Xense Robotics CEO Ma Daolin Publishes Op-Ed at th...
2026-08-26
Xense Robotics CEO Ma Daolin Publishes Op-Ed at th...
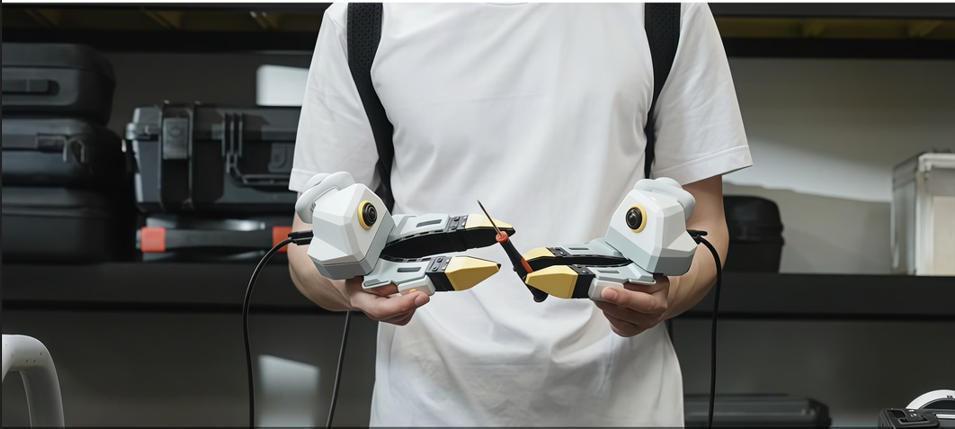
array:28 [ "id" => 43 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "WRC 2026 in Progress | Xense Tactile Perception Capabilities Continue to Evolve" "content" => "<p style="margin-bottom: 15px;">On August 19, the 2026 World Robot Conference officially opened at Yizhuang, Beijing.</p><p style="margin-bottom: 15px;">At this WRC, Xense Robotics appeared at booth A107, showcasing an integrated whole-hand tactile solution, the XTac UMI G1 wearable tactile data collection gripper, and interactive experiences with multimodal tactile sensors.</p><p style="margin-bottom: 15px;">At the exhibition site, the Xense booth attracted many professional visitors. Through pressing and sliding operations, visitors could observe in real time the sensor's perception feedback of 3D deformation, force distribution and slip state, and experience the high-quality tactile data collection process through the lightweight wearable collection device.</p><p style="margin-bottom: 15px;">Behind the lightweight hardware demonstration is Xense Robotics' technical path of continuously building a full-stack tactile ecosystem closed loop: starting from tactile hardware, connecting real interaction data, model training and scenario applications, so that touch goes beyond the sensor level and becomes the foundational capability for robots to understand and manipulate the physical world.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789452447866365.jpg" title="1789452447866365.jpg" alt="2026-08-21-WRC 2026进行时|千觉触觉感知能力持续进化.jpg"/></p><p style="margin-bottom: 15px;"><span style="font-size: 20px;"><strong>WRC Xense Exhibition Area</strong></span></p><p style="margin-bottom: 15px;"><strong>01 Whole-Hand Solution</strong></p><p style="margin-bottom: 15px;"><strong>Giving dexterous hands human-level tactile perception</strong></p><p style="margin-bottom: 15px;">This year, the industry's requirements for touch are undergoing a major shift: from "whether there is touch" to "whether there is high-quality touch suitable for dexterous hands." From fingertip to whole-hand tactile solutions, Xense's tactile perception capabilities are continuously evolving.</p><p style="margin-bottom: 15px;">In real manipulation, touch does not only occur at a single point. The fine contact at the fingertip, the force perception in the palm area, and the coordinated feedback among different positions together determine the depth of a robot's understanding of an object. Xense's whole-hand tactile solution combines fingertip tactile sensors with flexible electronic skin, extending perception coverage from fingertips to the entire hand, providing a more complete information foundation for dexterous manipulation.</p><p style="margin-bottom: 15px;"><strong>Xense Whole-Hand Tactile Solution</strong></p><p style="margin-bottom: 15px;">Among these, the fingertip tactile sensor relies on three-color-light visuo-tactile technology, integrating high-density perception capability within a bionic fingertip form, and can be used for tasks such as alignment, pushing, rolling contact and fine grasping, helping robots obtain richer and more detailed tactile information at the moment of contact. The palm area uses large-area flexible electronic skin, covering more dexterous hand regions and perceiving broader contact distribution and force changes.</p><p style="margin-bottom: 15px;">At the booth, visitors personally experienced pressing and sliding on the fingertip, gaining a more direct feel for how the sensor captures subtle deformation and force changes.</p><p style="margin-bottom: 15px;"><span style="font-size: 20px;"><strong>Visitors Experiencing Touch On Site</strong></span></p><p style="margin-bottom: 15px;"><strong>02 XTac UMI G1</strong></p><p style="margin-bottom: 15px;"><strong>Entering a high-quality data ecosystem with an efficient data collection system</strong></p><p style="margin-bottom: 15px;">Tactile hardware solves "how to perceive," while data collection answers "how to settle perception into data." The long-term competitiveness of embodied intelligence depends on whether one has high-quality, low-cost, sustainably accumulating real interaction data.</p><p style="margin-bottom: 15px;">Xense Wearable Tactile Data Collection Gripper</p><p style="margin-bottom: 15px;">The Xense XTac UMI G1 wearable tactile data collection gripper is designed precisely for this need. It consists of a master gripper, slave gripper, backpack computing unit, headset kit and visualization terminal, capable of synchronously collecting vision, touch, pose, gripper state and IMU data during natural human-robot interaction.</p><p style="margin-bottom: 15px;">The core value of this solution: it ensures high data quality — natively adapted for real-robot deployment with high data usability; and it does not require a real robot body for collection, greatly reducing the cost and threshold of data acquisition. Low cost, high efficiency and high usability make large-scale data collection possible.</p><p style="margin-bottom: 15px;">At WRC, visitors used the two-finger gripper to collect data on everyday objects such as lipstick, gum and business cards, and viewed the output of visual and tactile data on computers in real time, intuitively experiencing how real manipulation data is completely and accurately collected and presented.</p><p style="margin-bottom: 15px;">Hardware is just the starting point. Only when the contact information from real manipulation is preserved and becomes data that model training and product optimization can directly use does touch truly gain long-term value.</p><p style="margin-bottom: 15px;"><span style="font-size: 20px;">XTac UMI G1 on Display</span></p><p style="margin-bottom: 15px;"><strong>03 Interactive Experience Zone</strong></p><p style="margin-bottom: 15px;"><strong>Delicately perceiving textures, beyond force</strong></p><p style="margin-bottom: 15px;">At WRC, Xense Robotics set up a multimodal tactile sensor interactive experience. Visitors could observe in real time the sensor's perception results of contact state changes through pressing and sliding operations, intuitively understanding how tactile information is captured, presented and applied.</p><p style="margin-bottom: 15px;"><strong>Multimodal Tactile Sensor</strong></p><p style="margin-bottom: 15px;">The Xense tactile sensor series covers products including Quark N1, Elf, Photon, GS-PS and more, outputting multimodal data such as raw images, differential images, 3D visualization, tangential information, depth maps and six-axis force, supporting capabilities including 3D surface measurement, texture recognition, 3D force distribution, slip detection and motion tracking.</p><p style="margin-bottom: 15px;"><strong>Mahjong Texture Recognition Experience</strong></p><p style="margin-bottom: 15px;">In the texture recognition experience, visitors gently pressed a mahjong tile onto the flat sensor, and the software interface immediately presented the clearly visible raised texture data of the tile surface — engravings, character edges and embossed depth all clearly visible, with tactile information transformed into observable, measurable digital signals. This delicate perception extends touch beyond "what was felt" to "what was discerned."</p><p style="margin-bottom: 15px;">This display is not only an on-site interactive experience but also an intuitive window into Xense's tactile hardware and data capabilities: presenting tactile information in an observable, understandable and communicable way.</p><p style="margin-bottom: 15px;">Looking beyond the hardware on display, Xense Robotics' long-term technology direction is becoming increasingly clear: on one hand, the coverage of tactile perception extends from fingertips to the whole hand, and from industrial scenarios to humanoid robot applications — touch is entering more and more manipulation scenarios. On the other hand, through data collection devices such as the XTac UMI G1, Xense is the first in the industry to balance the relationship among data collection cost, efficiency and quality, making real interaction data a scalable asset.</p><p style="margin-bottom: 15px;">What Xense Robotics is building is a systematic capability centered on touch: acquiring real contact information through tactile hardware, settling real interaction processes through data collection systems, supporting model training with multimodal data, and ultimately continuing to deliver real robot manipulation tasks. In the process of robots moving into the real physical world, touch is not just a sensor module, but an important foundation spanning perception, data, models and applications.</p><p style="margin-bottom: 15px;">In the future, Xense will continue to bring tactile technology into more real manipulation scenarios, giving robots more reliable perception, higher-quality data and more stable manipulation capabilities as they engage with the world.</p><p><br/></p>" "thumb" => "/storage/images/20260915/abe9f3f26d263cc6e429d4c31bba9a1f.jpg" "auth" => "jsydl" "click" => 48 "edition" => 2 "keyword" => null "description" => "On August 19, the 2026 World Robot Conference officially opened at Yizhuang, Beijing." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789452457 "update_time" => null "release_time" => 1787241600 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 42 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Tactile-Native Breakthrough for Embodied Intelligence | Xense Robotics Builds a Full-Stack Tactile Ecosystem at WAIC 2026" "content" => "<p style="margin-bottom: 15px;">On July 17, the World Artificial Intelligence Conference (WAIC 2026) officially opened at the Shanghai World Expo Exhibition and Convention Center. Xense Robotics, deeply rooted in the tactile physical intelligence track, made a major appearance at this WAIC, with sustained high foot traffic and continuous consultation exchanges at the booth. At this exhibition, with "Touch Ignites Physical Intelligence" as its core, Xense centrally showcased the newly released VTLA embodied tactile model, visuo-tactile multimodal dataset, core data collection devices and tactile sensor hardware matrix, and brought multi-scenario real-world Demos and immersive tactile interaction experiences, comprehensively presenting Xense's "model-data-hardware" tactile-native intelligent technology ecosystem and industrial implementation strength, providing brand-new solutions for the large-scale implementation of embodied intelligence.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789452232447293.jpg" title="1789452232447293.jpg" alt="2026-07-18-触觉原生破局具身智能,千觉机器人WAIC 2026打造全栈触觉生态闭环.jpg"/></p><p style="margin-bottom: 15px;"><strong>01 VTLA Model-Driven</strong></p><p style="margin-bottom: 15px;"><strong>Three Real-Scenario Demos with Solid Implementation</strong></p><p style="margin-bottom: 15px;">At the Xense Robotics booth, a clear "hardware-data-model" technology ecosystem was vividly presented. The most attention-grabbing exhibits were the three real-scenario Demos driven by the VTLA (Vision-Tactile-Language-Action) multimodal model, jointly validating the core value of Xense's tactile-native technology route in real industrial scenarios.</p><p style="margin-bottom: 15px;">The dual-arm long-sequence carton forming Demo focuses on flexible materials, long sequences and strong-disturbance operation scenarios. Carton forming involves intricate procedures, requiring continuous multi-step linked actions including grasping, flattening, alignment, folding and pressing, during which material deformation, position offset and uneven force distribution easily occur. In the on-site demonstration, the robot did not merely complete standard actions in an ideal environment — under human interference such as visitors shifting the cardboard, it perceived the cardboard's force state and deformation in real time, dynamically adjusted the direction and magnitude of applied force, and smoothly completed the folding and forming of the carton. The entire process required no preset trajectories and was completed entirely through adaptive tactile feedback.</p><p style="margin-bottom: 15px;">The earphone precision assembly Demo targets millimeter-level fine operation scenarios in high-end manufacturing. Addressing the pain points of small irregular parts being prone to offset, jamming and extremely low fault tolerance, the robot can perceive edge collisions, pose deviations and micro slips in real time, autonomously completing precise alignment, stable placement and dynamic correction, fully validating the core value of tactile intelligence in high-end manufacturing scenarios such as 3C precision assembly, small-part sorting and flexible packaging — truly delivering the "last centimeter."</p><p style="margin-bottom: 15px;">The Dewu product authenticity identification Demo targets fully unmanned warehouse inspection scenarios. Facing items that look similar but differ in material, Xense Robotics collects multidimensional tactile features including texture, hardness and elasticity through the VTLA algorithm model and tactile sensors, and combined with the model's multimodal fusion capability, achieves non-destructive removal and replacement of insoles, followed by authenticity verification by Dewu's cloud platform. This capability has extremely high practical value in scenarios such as consumer product authenticity identification and industrial quality inspection.</p><p style="margin-bottom: 15px;">The common feature of the three Demos: they are not "performance-style" demonstrations with preset trajectories, but adaptive operations truly driven by tactile-native technology. This is precisely where the core competitiveness of Xense's solutions lies.</p><p style="margin-bottom: 15px;"><strong>02 XTac UMI G1 and Sensor Matrix</strong></p><p style="margin-bottom: 15px;"><strong>Consolidating the Data and Perception Foundation</strong></p><p style="margin-bottom: 15px;">XTac UMI G1: filling the tactile data gap. The XTac UMI G1 wearable visuo-tactile multimodal data collection gripper exhibited on site directly addresses the common challenges of scarce real interaction data, missing tactile modality and high collection cost in the embodied intelligence field. The device integrates high-precision visuo-tactile sensors, an IMU inertial measurement unit and high-resolution encoders, capable of synchronously collecting five-dimensional core data including vision, touch, pose trajectory and gripper state, transforming contact changes, force feedback and slip trends during real human operation into high-quality embodied datasets that can be annotated, replayed and trained. As the core carrier of Xense's technology closed loop, the XTac UMI G1 effectively fills the tactile data gap in embodied model training.</p><p style="margin-bottom: 15px;">Sensor matrix and whole-hand tactile solution. Xense's full series of multimodal tactile sensor product matrix was also showcased, comprehensively covering fingertip, gripper, flat and curved form factors, along with a newly upgraded waterproof tactile hardware product. At the same time, Xense publicly demonstrated its whole-hand tactile solution for the first time, building a full-hand multi-point tactile feedback network based on fingertip tactile sensors and electronic skin modules, achieving real-time perception of contact position, force magnitude, slip changes and contact state across the entire hand, marking the evolution of robot tactile perception from "local single-point perception" toward "complete intelligent hand understanding."</p><p style="margin-bottom: 15px;">In the immersive tactile interaction experience zone at the booth, visitors could control the game process in real time through simple actions such as light touch, pressing and force adjustment. The sensor's millisecond-level response speed and fine pressure recognition capability let the public directly experience the ultra-high sensitivity and stability of Xense tactile sensors, truly experiencing the broad application prospects of tactile technology in civil scenarios such as human-robot interaction, virtual reality and remote control.</p><p style="margin-bottom: 15px;"><strong>03 Pioneering the Tactile-Native Route</strong></p><p style="margin-bottom: 15px;"><strong>Leading the Wave of Embodied Intelligence Industrialization</strong></p><p style="margin-bottom: 15px;">This comprehensive appearance at WAIC 2026 is a concentrated implementation showcase of Xense's "model-data-hardware" technology ecosystem, and also marks the official entry of China's tactile physical intelligence into a new stage of industrialization and large-scale implementation.</p><p style="margin-bottom: 15px;">From vision-based "seeing the world" to tactile-native "understanding and interacting with the world," Xense, through independent and controllable underlying technology innovation, has completely broken the limitations of traditional robot mechanical execution, achieving a capability leap of autonomous perception, autonomous adaptation and dynamic operation.</p><p style="margin-bottom: 15px;">In the future, Xense Robotics will continue to deepen the tactile-native track, continuously iterating the X-TouchMind V1 model, TacVerse dataset and tactile hardware system, and continuously breaking through physical intelligence technology bottlenecks. Xense will focus on core scenarios including industrial precision assembly, flexible logistics, intelligent inspection, consumer product authenticity identification and data center construction, continuously deepening industry ecosystem cooperation, and with a complete tactile intelligence foundation, empowering the high-quality development of the embodied intelligence industry and leading the new wave of the physical intelligence era.</p><p><br/></p>" "thumb" => "/storage/images/20260915/9b8e3c733f574ef89ed23e54e1d2edc8.jpg" "auth" => "jsydl" "click" => 52 "edition" => 2 "keyword" => null "description" => "On July 17, the World Artificial Intelligence Conference (WAIC 2026) officially opened at the Shanghai World Expo Exhibition and Convention Center. Xense Robotics, deeply rooted in the tactile physical intelligence track, made a major appearance at this WAIC, with sustained high foot traffic and continuous consultation exchanges at the booth. At this exhibition, with "Touch Ignites Physical Intelligence" as its core, Xense centrally showcased the newly released VTLA embodied tactile model, visuo" "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789452235 "update_time" => null "release_time" => 1784304000 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 41 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Major Release | Xense Robotics Launches the First VTLA Embodied Tactile Model X-TouchMind V1 and the First Visuo-Tactile Multimodal Dataset TacVerse 1k" "content" => "<p style="margin-bottom: 15px;">From seeing the world to manipulating the world</p><p style="margin-bottom: 15px;">Building a full-stack tactile intelligence ecosystem from tactile perception and data collection to embodied intelligence</p><p style="margin-bottom: 15px;">The Next Challenge for Embodied Intelligence: From Post-Hoc Modality to Tactile-Native</p><p style="margin-bottom: 15px;">X-TouchMind V1: Xense's First Tactile Embodied Foundation Model</p><p style="margin-bottom: 15px;">TacVerse 1k: The First 1,000 Hours of High-Quality Visuo-Tactile Multimodal Embodied Dataset</p><p style="margin-bottom: 15px;">Driving large-scale implementation of physical intelligence for real industrial tasks</p><p style="margin-bottom: 15px;">Building a full-stack tactile intelligence ecosystem</p><p style="margin-bottom: 15px;">from tactile perception and data collection</p><p style="margin-bottom: 15px;">to embodied intelligence</p><p style="margin-bottom: 15px;">Xense Robotics officially released its first VTLA embodied tactile model, X-TouchMind V1, along with the first visuo-tactile multimodal embodied dataset for real physical interaction, TacVerse 1k.</p><p style="margin-bottom: 15px;">This release marks the completion of Xense Robotics' complete technology ecosystem from tactile hardware systems and data collection systems to data assets and embodied models, further advancing tactile intelligence from perception capability toward robot intelligence capability.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789451998182018.jpg" title="1789451998182018.jpg" alt="微信图片_20260914151539_227_150.jpg"/></p><p style="margin-bottom: 15px;"><strong>01 The Next Challenge for Embodied Intelligence:</strong></p><p style="margin-bottom: 15px;"><strong>From Post-Hoc Modality to Tactile-Native</strong></p><p style="margin-bottom: 15px;">As robots move toward real-world applications, relying solely on vision technology can no longer meet complex task requirements. However, post-hoc tactile information often requires a splicing-style path to integrate into existing embodied models, limiting the ceiling of physical interaction capability.</p><p style="margin-bottom: 15px;">Facing this industry bottleneck,</p><p style="margin-bottom: 15px;">Xense believes that touch is the key modality for robots to truly enter the physical world, and must be built full-stack around real high-contact scenarios based on a native ecosystem,</p><p style="margin-bottom: 15px;">so that robots can not only perceive the world but also understand and reliably complete complex physical tasks.</p><p style="margin-bottom: 15px;"><strong>02 X-TouchMind V1:</strong></p><p style="margin-bottom: 15px;"><strong>Xense's First VTLA Embodied Tactile Model</strong></p><p style="margin-bottom: 15px;">X-TouchMind V1 is a VTLA embodied tactile model trained by Xense on visuo-tactile multimodal data.</p><p style="margin-bottom: 15px;">X-TouchMind V1 focuses more on the physical state after contact occurs, jointly modeling vision, language, touch, action and robot body state, achieving coordinated modeling from task understanding and action generation to contact feedback control.</p><p style="margin-bottom: 15px;">The model adopts a layered architecture corresponding to different levels of real robot manipulation:</p><p style="margin-bottom: 15px;">System 2: task understanding and semantic reasoning layer, responsible for understanding the environment, task goals and language instructions, answering "what to do."</p><p style="margin-bottom: 15px;">System 1: action generation and trajectory planning layer, generating action paths based on vision, task semantics and robot state, answering "how to do it."</p><p style="margin-bottom: 15px;">System 0: tactile-body interaction control layer, using tactile and body feedback for high-frequency correction during real contact, answering "how to do it steadily and accurately after contact."</p><p style="margin-bottom: 15px;">Through this architecture, X-TouchMind V1 can not only generate action sequences, but also understand slip, force, deformation, texture and contact stability during real manipulation, dynamically correcting actions, thereby improving robot stability in tasks such as fine manipulation, flexible material handling and intelligent inspection.</p><p style="margin-bottom: 15px;">For Contact-Rich tasks such as pushing aside, pulling out, pressing together, inserting, aligning and restoring, X-TouchMind V1's goal is not to have the robot complete a one-off action demonstration, but to enable the robot to "do the job well" reliably, safely and without damage in complex physical interactions.</p><p style="margin-bottom: 15px;"><strong>03 TacVerse 1k:</strong></p><p style="margin-bottom: 15px;"><strong>The First 1,000 Hours of High-Quality Visuo-Tactile Multimodal Embodied Dataset</strong></p><p style="margin-bottom: 15px;">Released alongside X-TouchMind V1, TacVerse 1k is Xense's first 1,000-hour high-quality visuo-tactile multimodal embodied dataset built for real physical interaction.</p><p style="margin-bottom: 15px;">On the data collection side, TacVerse 1k relies on Xense's self-developed collection hardware system, decoupling data production from the robot body, achieving production capacity decoupling, scenario decoupling and body reuse. Based on this system, data collection costs can drop by more than 80%, with efficiency improved 3 to 5 times, providing the foundation for large-scale real interaction data accumulation.</p><p style="margin-bottom: 15px;">On the data quality side, Xense's self-developed XTacFlow is responsible for unified scheduling of the collection pipeline, supporting unified access of multiple devices, millisecond-level cross-modal time alignment, and achieving over 90% automation in data return and post-processing, transforming raw multimodal data into trainable, traceable, reusable data samples and training assets.</p><p style="margin-bottom: 15px;">TacVerse 1k's data structure is natively compatible with mainstream robot data formats including LeRobot, MCAP, HDF5 and ROS2, and standardizes tactile modality extension fields, so the data is not only usable internally at Xense but also provides a foundation for industry sharing, reuse and benchmarking.</p><p style="margin-bottom: 15px;">According to the release plan, the first 100 hours of the TacVerse 1k dataset will open for applications on July 30, covering 40+ real scenarios; starting in August, applications for the 1,000-hour dataset will open in batches, with open cooperation advanced through platforms such as Alibaba ModelScope and Hugging Face.</p><p style="margin-bottom: 15px;">The simultaneous release of X-TouchMind V1 and TacVerse 1k marks Xense's official entry into a new stage of industrial implementation.</p><p style="margin-bottom: 15px;">Going forward, Xense will focus on in-depth industry cooperation in scenarios including industrial precision assembly, consumer electronics assembly, flexible logistics, intelligent inspection, consumer product authenticity identification and data center construction.</p><p style="margin-bottom: 15px;">A representative of Xense Robotics said: "We hope the release of X-TouchMind V1 and TacVerse 1k will continue to provide value to the industry, opening a new stage of industrial implementation with 'tactile-native.'"</p><p style="margin-bottom: 15px;">In the future, Xense will continue to advance technology iteration and theoretical exploration around "tactile-native" and "real scenarios," progressing together with the industry.</p><p><br/></p>" "thumb" => "/storage/images/20260915/d358c953772cd9c605abdb43876cf7b0.jpg" "auth" => "jsydl" "click" => 52 "edition" => 2 "keyword" => null "description" => "Xense Robotics officially released its first VTLA embodied tactile model, X-TouchMind V1, along with the first visuo-tactile multimodal embodied dataset for real physical interaction, TacVerse 1k." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789452009 "update_time" => null "release_time" => 1784131200 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 40 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Xense Robotics Completes Hundred-Million-RMB Financing, Accelerating Tactile Perception, Data and Model System Implementation" "content" => "<p style="margin-bottom: 15px;">Recently, Xense Robotics Technology (Shanghai) Co., Ltd. completed a financing round exceeding RMB 100 million. This round was strategically invested by a top embodied intelligence industry player and Jide Electric, with co-investment from Tianji Capital.</p><p style="margin-bottom: 15px;">The funds will be focused on three major directions: accelerating the industrialization of high-precision three-color-light visuo-tactile sensors; advancing the deployment and validation of visuo-tactile data collection devices and large-scale tactile datasets in real scenarios; and continuously improving physical intelligence models natively supporting touch and contact modalities, accelerating their application and transformation in key embodied intelligence tasks.</p><p style="margin-bottom: 15px;"><strong>From "Seeing the World" to "Contacting the World"</strong></p><p style="margin-bottom: 15px;">When robots enter real scenarios such as factories, warehouses, retail and homes, relying solely on vision and language is not enough to complete complex manipulations.</p><p style="margin-bottom: 15px;">Micro deviations in precision assembly, deformation when grasping flexible objects, contact pressure in grinding and inspection, and force control when handling fragile items all require the robot to understand: what it touched, how much force it applied, whether slip occurred, and how to adjust next.</p><p style="margin-bottom: 15px;">Touch is becoming a critical capability for embodied intelligence to move from demonstration to usability, and from usability to reliability.</p><p style="margin-bottom: 15px;"><strong>Advancing Application Validation in Real Scenarios</strong></p><p style="margin-bottom: 15px;">Currently, Xense Robotics is advancing validation and applications in scenarios including embodied dexterous manipulation, industrial precision assembly, tactile inspection, flexible logistics and home intelligent agents, having served more than 300 leading industry customers.</p><p style="margin-bottom: 15px;">In tasks such as precision assembly, quality inspection, flexible object manipulation and human-robot collaboration, accurate perception of contact state will directly affect task stability, yield rate, safety and generalization capability.</p><p style="margin-bottom: 15px;">After this financing round, Xense Robotics will continue investing in the R&D and industrialization of tactile perception, tactile data and tactile intelligence models, advancing robots from "seeing, hearing and planning" toward "contacting, manipulating and completing tasks."</p><p><img src="/file/ueditor/php/upload/image/20260915/1789451538792089.jpg" title="1789451538792089.jpg" alt="2026-07-14-千觉机器人完成亿元融资,加速触觉感知、数据与模型体系落地.jpg"/></p>" "thumb" => "/storage/images/20260915/106b759d05cd1437198fed305dd88147.jpg" "auth" => "jsydl" "click" => 44 "edition" => 2 "keyword" => null "description" => "Recently, Xense Robotics Technology (Shanghai) Co., Ltd. completed a financing round exceeding RMB 100 million. This round was strategically invested by a top embodied intelligence industry player and Jide Electric, with co-investment from Tianji Capital." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789451548 "update_time" => null "release_time" => 1783958400 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 39 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Xense Named a WEF Technology Pioneer | Defining the Future Path of Embodied Intelligence with Tactile Foresight" "content" => "<p style="margin-bottom: 15px;"><strong>From seeing the world to manipulating the world</strong></p><p style="margin-bottom: 15px;"><strong><img src="/file/ueditor/php/upload/image/20260915/1789451233827074.png" title="1789451233827074.png" alt="2026-06-10-千觉入选WEF科技先锋企业|以触觉前瞻,定义具身智能的未来路径.png"/></strong></p><p style="margin-bottom: 15px;">On June 10, the World Economic Forum announced its 2026 Technology Pioneers list. Xense Robotics Technology (Shanghai) Co., Ltd. was selected into the 2026 global Technology Pioneers community, and founder and CEO Ma Daolin will represent the company in World Economic Forum global agenda discussions and innovator community activities.</p><p style="margin-bottom: 15px;">Founded in 2000, the World Economic Forum Technology Pioneers community targets early-stage to growth-stage technology companies worldwide, focusing on innovative companies that are designing, developing and deploying frontier technologies with the potential to significantly impact business and society.</p><p style="margin-bottom: 15px;">For Xense, this selection is not only recognition by a global innovation platform, but also signifies that tactile intelligence — a key technology direction for the physical intelligence era — is entering the broader global technology and industry agenda.</p><p style="margin-bottom: 15px;"><strong>Industry Transformation</strong></p><p style="margin-bottom: 15px;">At a time when large model technology is rapidly proliferating and embodied intelligence is accelerating implementation, the entire robotics industry is facing a critical inflection point: the bottleneck of intelligence relying solely on vision is becoming increasingly evident. Vision can help robots "see the environment and recognize objects," but cannot understand real physical properties such as weight, hardness, friction and deformation, leaving robots able only to "see but not feel, and not perform well," struggling to handle high-precision, high-reliability operation scenarios such as assembly, grinding, flexible grasping and precision manipulation.</p><p style="margin-bottom: 15px;">Industry consensus is becoming increasingly clear: many robot task failures are not because robots "cannot see," but because machines cannot perceive what happens after contact. If vision intelligence solved the entry-level problem of robot perception, then tactile perception and physical intelligence are the core foundations supporting robots to truly integrate into the real physical world and achieve high-level autonomous operation. Future industrial robots, humanoid robots and various embodied intelligent agents, to enter complex industrial scenarios and human living environments and achieve stable, precise, safe and autonomous physical interaction, will find high-precision, modelable, computable tactile capability an indispensable underlying core capability.</p><p style="margin-bottom: 15px;">It is precisely based on deep thinking about the underlying logic of the embodied intelligence industry and long-term foresight that Xense Robotics was successfully selected for the World Economic Forum (WEF) Technology Pioneers list. Standing out among a host of frontier technology companies, this heavyweight global honor is not only authoritative recognition of Xense's technology innovation capability, research strength, engineering implementation level and long-term industrial value, but also a global endorsement of the company's long-adhered "touch-first, physical intelligence" technology route.</p><p style="margin-bottom: 15px;">Most current industry solutions remain at the level of stacking optimization of vision intelligence and general algorithms, and WEF's recognition further proves: the real breakthrough of next-generation embodied intelligence lies in tactile perception and physical understanding. The track Xense has laid out ahead of time and continuously cultivated is precisely the core trend leading the industry's future upgrade.</p><p style="margin-bottom: 15px;">As one of the world's most authoritative and influential technology innovation selections, the WEF Technology Pioneers has long focused on emerging companies in early-stage to growth-stage with original technology and industrial transformation potential. Past honorees include global benchmark companies such as Google, PayPal and Spotify. This selection means Xense's original technology route, R&D system and implementation capability have gained recognition from a global innovation platform.</p><p style="margin-bottom: 15px;">Xense has carried a deep academic and engineering heritage since its founding. The company was founded by Ma Daolin, a professor at Shanghai Jiao Tong University, PhD from Peking University, MIT postdoc, and winner of the only Best Paper Award at ICRA 2021. The core team has long been deeply engaged in robot manipulation, tactile perception and embodied intelligence frontiers. Based on long-term accumulation, Xense proposed the "tactile spatial intelligence" theory early on, and has continuously advanced a full-stack self-developed closed loop from underlying sensor design, tactile data collection, perception algorithms, tactile large models to robot control.</p><p style="margin-bottom: 15px;">More importantly, Xense has always insisted on landing these capabilities in real scenarios. The company does more than provide tactile sensors; it is committed to building a general tactile foundation for the embodied intelligence era, enabling robots to perceive physical properties, understand contact states, adapt autonomously to complex environments and complete fine manipulation — continuously driving embodied intelligence from the "visual perception era" toward the true "physical intelligence era."</p><p><br/></p>" "thumb" => "/storage/images/20260915/640a8f9c48e212e4461d6bdd322a85cb.png" "auth" => "jsydl" "click" => 38 "edition" => 2 "keyword" => null "description" => "On June 10, the World Economic Forum announced its 2026 Technology Pioneers list. Xense Robotics Technology (Shanghai) Co., Ltd. was selected into the 2026 global Technology Pioneers community, and founder and CEO Ma Daolin will represent the company in World Economic Forum global agenda discussions and innovator community activities." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789451255 "update_time" => 1789616095 "release_time" => 1781020800 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 38 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Touch Ignites Physical Intelligence! Xense Showcases the VTLA Model and Tactile Data Collection Devices at ICRA 2026, Demonstrating Hardcore Strength" "content" => "<p style="margin-bottom: 15px;"><strong>From seeing the world to manipulating the world</strong></p><p style="margin-bottom: 15px;">In the era of rapidly iterating embodied intelligence, touch is the core key to robots reading the physical world and reliably completing real manipulation tasks.</p><p style="margin-bottom: 15px;">Exploring the frontiers of visuo-tactile fusion technology with global top experts, advancing embodied intelligence from the laboratory to the real world.</p><p style="margin-bottom: 15px;">Xense co-founder and CTO Zhao Haonan shared the latest progress in full-stack tactile technology on site; founder Ma Daolin joined a Panel roundtable discussion and presented the award to the winner of Best Paper for Tactile Representation at the closing session, exploring the future direction of visuo-tactile intelligence together with global academic and industry guests.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789451114301029.jpg" title="1789451114301029.jpg" alt="2026-06-05-触觉点亮物理智能!千觉携VTLA模型与触觉数采设备亮相ICRA 2026,秀出硬核实力.jpg"/></p><p style="margin-bottom: 15px;">From June 2 to June 4, the global robotics top conference ICRA 2026 grandly opened in Vienna, Austria. Xense Robotics appeared at Hall B-123, bringing its full suite of tactile intelligence technology achievements to the international stage, demonstrating with visible, verifiable and experienceable real-scenario Demos to the global academic and industrial community: exclusive tactile perception and physical interaction capability is the core breakthrough for robots to leave the laboratory and adapt to real, ever-changing physical scenarios.</p><p style="margin-bottom: 15px;">The core answer to future physical intelligence lies in "tactile intelligence."</p><p style="margin-bottom: 15px;"><strong>01 Real-Scenario Implementation Challenges Must Ultimately Be Solved by Touch</strong></p><p style="margin-bottom: 15px;">As robot intelligence continues to upgrade and scenario adaptation and operation precision keep improving, many implementation gaps remain in real unstructured physical scenarios. The core pain points of various complex operation scenarios are mostly concentrated at the moment of physical contact: flexible materials deform easily, operation force is difficult to control precisely, micro slips cannot be perceived in time, and contact fit states cannot be judged precisely...</p><p style="margin-bottom: 15px;">These micro physical changes occurring after contact are the core difficulties of precise robot operation, directly determining the success, failure and stability of tasks such as grasping, folding, assembly and alignment. Only with precise perception of physical interaction can stable real-world operation be achieved.</p><p style="margin-bottom: 15px;">To truly adapt to complex real scenarios and achieve large-scale implementation, robots must fill the core underlying capability gap — high-precision tactile perception and autonomous physical interaction capability.</p><p style="margin-bottom: 15px;">This is also the core theme of Xense's ICRA 2026 booth: igniting physical intelligence with touch, giving robots the core capabilities of perceiving physics, understanding interaction and operating autonomously.</p><p style="margin-bottom: 15px;"><strong>02 On-Site Core Highlights</strong></p><p style="margin-bottom: 15px;">Validating the VTLA Model's High-Difficulty Long-Sequence Operation Under Interference</p><p style="margin-bottom: 15px;">The biggest highlight of the booth was the tactile-driven dual-arm long-sequence carton forming demonstration under external interference conditions.</p><p style="margin-bottom: 15px;">A seemingly simple carton folding task is actually a typical "high-difficulty flexible long-flow task" in robotics: thin and easily deformable materials, no fixed motion trajectory, and dynamically changing contact states. Especially after external interference, the cardboard's position, force state and contact relationships all change, placing higher demands on the robot's real-time perception, action adjustment and task recovery capabilities.</p><p style="margin-bottom: 15px;">Unlike the fixed pattern of traditional robots with preset trajectories and mechanical action replication, Xense's solution focused on demonstrating the model's adaptive adjustment capability under interference. After external disturbance occurs, the system can re-judge the cardboard's current state based on real-time tactile and visual feedback, perceive pose offset, force changes and material deformation, and autonomously correct dual-arm coordinated actions, resuming subsequent folding, pressing and other task steps, maintaining operation continuity in dynamically changing real environments.</p><p style="margin-bottom: 15px;">This is also the key value of physical intelligence in real scenarios: not just completing tasks under ideal conditions, but continuing to perceive, judge and adjust while contact states are broken and environments change, stably completing the task.</p><p style="margin-bottom: 15px;"><strong>03 Global Premiere | Building a Tactile Data Closed Loop, Completing the Physical Intelligence Data Gap</strong></p><p style="margin-bottom: 15px;">Tactile perception is the "physical nervous system" of robots, and high-quality tactile data is the core cornerstone of continuous iteration and capability evolution of embodied intelligence.</p><p style="margin-bottom: 15px;">At this exhibition, Xense brought the TacCap-Gripper tactile data collection device for its global debut.</p><p style="margin-bottom: 15px;">Targeting high-frequency operation scenarios such as robot grasping, gripping and precision assembly, this wearable data collection device integrates multi-dimensional high-precision perception units, capable of synchronously collecting action and tactile fusion data, precisely recording micro physical interaction details invisible to the naked eye such as contact start/end states, pressure distribution, material deformation and slip fluctuations.</p><p style="margin-bottom: 15px;">It transforms vague, unquantifiable physical contact behaviors into collectable, modelable, trainable high-quality embodied data, thoroughly filling the core data gap in robot fine operation, adaptive policy iteration and embodied model training, laying a solid data foundation for the large-scale evolution of physical intelligence.</p><p style="margin-bottom: 15px;"><strong>04 Full-Matrix Sensor Showcase, Covering All-Scenario Tactile Perception Needs</strong></p><p style="margin-bottom: 15px;">Beyond the major Demo and debut products, Xense also showcased its full series of multimodal tactile sensor product matrix, covering fingertip, gripper, flat and curved form factors, adapting to diverse intelligent carriers including dexterous hands, industrial robotic arms, humanoid robots and flexible interaction devices.</p><p style="margin-bottom: 15px;">The full hardware lineup can precisely capture micro textures, subtle deformations and multidimensional force changes, delivering high-precision, high-response, high-stability tactile perception, providing core underlying support for complex operation tasks such as fine alignment, pushing, rolling and precision grasping, fully presenting Xense's full-stack tactile technology accumulation from independent hardware R&D, data collection and algorithm optimization to scenario implementation.</p><p style="margin-bottom: 15px;"><strong>05 Fun Interactive Experience</strong></p><p style="margin-bottom: 15px;">To make hardcore tactile technology more intuitive and accessible, the booth also set up a tactile interactive game experience zone.</p><p style="margin-bottom: 15px;">Breaking away from traditional mechanical joystick control, visitors could control the game process in real time with just light touch, pressing and changes in force intensity. With millisecond-level response speed and fine pressure recognition, every on-site visitor could personally experience the ultra-high sensitivity and stable perception performance of Xense tactile sensors, intuitively understanding the core charm of tactile intelligence empowering machine interaction.</p><p style="margin-bottom: 15px;"><strong>Touch: The Last Mile to Physical Intelligence</strong></p><p style="margin-bottom: 15px;">Touch is the core foundation of robot physical intelligence and the fundamental support for precise interaction and stable real-world operation.</p><p style="margin-bottom: 15px;">As robots deeply land in real scenarios such as industrial precision manufacturing, flexible logistics, intelligent inspection and humanoid interaction, tactile-based physical interaction, force control adaptation and flexible operation capabilities have become indispensable standard core capabilities of advanced embodied intelligence.</p><p style="margin-bottom: 15px;">As a hardcore technology enterprise deeply rooted in the tactile intelligence track, Xense Robotics adheres to "Touch Ignites Physical Intelligence" as its core, continuously iterating high-precision sensing hardware, improving the tactile data ecosystem, optimizing perception and control algorithms, and advancing tactile technology from the laboratory to large-scale real-scenario implementation, giving more intelligent machines the core capabilities to precisely perceive, deeply understand and stably operate the real physical world.</p><p><br/></p>" "thumb" => "/storage/images/20260915/a9a4345d230eadfe63907fa49c5c0a89.jpg" "auth" => "jsydl" "click" => 35 "edition" => 2 "keyword" => null "description" => "In the era of rapidly iterating embodied intelligence, touch is the core key to robots reading the physical world and reliably completing real manipulation tasks." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789451123 "update_time" => null "release_time" => 1780588800 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 37 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Xense Robotics at ICRA 2026 Workshop: For Real-World Manipulation, Robots Need a "Tactile Foundation"" "content" => "<p style="margin-bottom: 15px;">From seeing the world to manipulating the world, exploring the frontiers of visuo-tactile fusion technology with global top experts, advancing embodied intelligence from the laboratory to the real world.</p><p style="margin-bottom: 15px;">Xense co-founder and CTO Zhao Haonan shared the latest progress in full-stack tactile technology on site; founder Ma Daolin joined a Panel roundtable discussion and presented the award to the winner of Best Paper for Tactile Representation at the closing session, exploring the future direction of visuo-tactile intelligence together with global academic and industry guests.</p><p style="margin-bottom: 15px;">Recently, the world's leading conference in robotics and automation, the 2026 IEEE International Conference on Robotics and Automation (ICRA 2026), was held in Vienna, Austria. In parallel, the 7th ViTac Workshop (Vision and Touch workshop) was successfully convened, with Xense Robotics invited to participate and generously supporting the event as its highest-level sponsor, exploring visuo-tactile technology frontiers with global top experts and advancing embodied intelligence from the laboratory to the real world.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789450945224295.jpg" title="1789450945224295.jpg" alt="2026-06-01-千觉机器人亮相-ICRA-2026-Workshop:面向真实世界操作,机器人需要一套“触觉底座”.jpg"/></p><p style="margin-bottom: 15px;"><strong>Touch Is Becoming an Important Frontier of Embodied Intelligence</strong></p><p style="margin-bottom: 15px;">This ICRA 2026 Workshop was themed "Learning to See and Feel: Vision-Tactile Synergy for Embodied AI," focusing on the use of vision and touch in robot manipulation. As robots move into real, unstructured environments, touch is becoming a critical capability for understanding physical information such as contact, force feedback, slip, deformation and material properties.</p><p style="margin-bottom: 15px;">In recent years, the development of new tactile hardware, high-fidelity simulation, and vision-tactile-language-action models is advancing robot tactile intelligence from single-point perception toward systematic capability. Around key topics including tactile hardware, tactile data collection, simulation, foundation models and contact-rich manipulation, the workshop provided a frontier exchange platform for academia and industry.</p><p style="margin-bottom: 15px;"><strong>From Hardware Perception to Data Closed Loop, Building a Physical Intelligence "Tactile Foundation"</strong></p><p style="margin-bottom: 15px;">At this conference, Xense Robotics co-founder and CTO Zhao Haonan delivered a keynote on tactile perception and physical intelligence, clearly articulating a key industry judgment: for robots to truly land in the real world, they must establish a tactile-driven physical intelligence system.</p><p style="margin-bottom: 15px;">Based on this judgment, Xense Robotics systematically presented the company's core achievements and technology layout in high-precision tactile sensing, tactile simulation, tactile algorithms and related fields. Centered on the core concept of "Igniting Physical Intelligence with Touch," it detailed core technologies including self-developed multimodal tactile sensors, the Isaac Sim tactile simulation platform, and the TouchGuide tactile guidance strategy, as well as application explorations in scenarios such as industrial precision assembly, flexible grasping and human-robot interaction. These explorations jointly advance touch from single-point sensor capability to the underlying general capability for robots to understand contact, execute fine manipulation and adapt to complex environments.</p><p style="margin-bottom: 15px;">As one of the world's earliest hardcore technology companies to propose the tactile spatial intelligence theory, Xense Robotics has always focused on building a robot tactile intelligence system. The company's self-developed multimodal tactile sensors can precisely capture high-density contact images, deformation signals and real-time force data, achieving multidimensional perception including motion, slip and force, adapting to irregular curved surfaces and flexible materials, providing "tactile nerve" support for fine robot manipulation. Related technologies won the only Best Conference Paper Award at ICRA 2021.</p><p style="margin-bottom: 15px;">On the technology innovation front, leveraging the Isaac Sim tactile simulation platform, Xense generates multimodal interaction data at low cost; innovating tactile calibration, compliant perception and the TouchGuide guidance strategy significantly improves robot reliability in complex tasks such as threading, assembly and flexible grasping, as well as the "last mile" of fine manipulation.</p><p style="margin-bottom: 15px;">To date, Xense has built a physical intelligence full-stack closed-loop ecosystem deeply integrating tactile hardware R&D, high-precision tactile data collection, self-developed perception algorithm iteration, tactile world model construction and VTLA model scenario application, to achieve self-evolution and sustained leadership of the physical intelligence system.</p><p style="margin-bottom: 15px;"><strong>Future Outlook: Let Robots Understand and Manipulate the World Through Contact</strong></p><p style="margin-bottom: 15px;">For embodied intelligence, the key challenges of real-world manipulation often lie after contact. Whether an object slips, whether a surface is soft, whether contact is stable, whether force is appropriate — these pieces of information are difficult to judge by vision alone, yet directly determine robot performance in tasks such as grasping, assembly, handover, alignment and rolling contact.</p><p style="margin-bottom: 15px;">Xense firmly believes that touch is the key entry point to physical intelligence. Only when robots can simultaneously see and feel the world can they correct actions in real time in complex physical interactions, moving from "executing actions" to "understanding interactions."</p><p style="margin-bottom: 15px;">In the future, Xense Robotics will continue to work toward the goal of "making touch scalable, learnable and deployable," focusing on four major directions: tactile perception upgrade, dataset construction, simulation optimization and model fusion, joining hands with global research institutions and industry partners to jointly advance the technological innovation and large-scale implementation of tactile intelligence, making touch the general core capability of next-generation embodied intelligence.</p><p><br/></p>" "thumb" => "/storage/images/20260915/d6ccc24c9da1a59e3c22655926fd70d1.jpg" "auth" => "jsydl" "click" => 41 "edition" => 2 "keyword" => null "description" => "From seeing the world to manipulating the world, exploring the frontiers of visuo-tactile fusion technology with global top experts, advancing embodied intelligence from the laboratory to the real world." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789450959 "update_time" => null "release_time" => 1780243200 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 36 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Xense Robotics at the 7th Y50 Forum: Showcasing the Power of Youth Hard-Tech Entrepreneurship Through Tactile Perception" "content" => "<p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789450797568987.jpg" title="1789450797568987.jpg" alt="2026-05-11-千觉机器人亮相第七届 Y50:以触觉感知展示青年硬科技创业力量.jpg"/></p><p style="margin-bottom: 15px;">On May 10, the 7th Shanghai Youth Innovation and Entrepreneurship 50 Forum was held in Shanghai. This Y50, themed "Youth and City Growing Together," brought together young entrepreneurs, investors, universities, industry and urban resources, jointly presenting the innovative vitality of Shanghai's youth science and innovation ecosystem.</p><p style="margin-bottom: 15px;">During the event, Xense Robotics participated in Y50-related activities as a representative of youth hard-tech enterprises. On one hand, Xense Robotics founder and CEO Dr. Ma Daolin joined the CBN Y50 live broadcast, discussing the topic of "a two-way pursuit between investors and Gen Z entrepreneurs"; on the other hand, Xense Robotics appeared at the Shanghai Youth Science and Innovation Carnival's Shanghai Jiao Tong University venue, showcasing the company's technical capabilities in embodied touch, precision robot manipulation and intelligent inspection.</p><p style="margin-bottom: 15px;">As an important platform for youth innovation and entrepreneurship in Shanghai, Y50 is not just a forum but also a bridge connecting young entrepreneurs, universities, industry, capital and urban resources. For hard-tech startup companies, such a platform is especially important, because hard tech going from the laboratory to industry cannot be separated from the joint support of real scenarios, industrial resources, long-term capital and the talent ecosystem.</p><p style="margin-bottom: 15px;">Xense Robotics' participation in Y50 was both a corporate showcase and a concentrated appearance of a young scientist startup team in Shanghai's science and innovation ecosystem. Starting from the underlying technology of robot tactile perception, the company continues to explore implementation paths for embodied intelligence in real industrial scenarios.</p><p style="margin-bottom: 15px;">In the CBN Y50 live broadcast, Dr. Ma Daolin shared his views on topics including young scientist entrepreneurship, the long-termism of hard tech, and the relationship between investors and entrepreneurs.</p><p style="margin-bottom: 15px;">In his view, hard-tech entrepreneurship is not about chasing short-term trends, but choosing a direction that is difficult enough yet truly worth pursuing long-term. For the embodied intelligence and robotics industry, vision lets robots "see" the world, while touch gives robots the opportunity to truly "manipulate" the world. Only with the ability to perceive contact, force, slip and physical interaction can robots move from demonstration to real applications.</p><p style="margin-bottom: 15px;">On the "two-way pursuit" between investors and entrepreneurs, Dr. Ma Daolin believes that capital should not be merely financial support, but a collaborative force for technology entering industrial scenarios. For hard-tech companies, a truly good investment relationship is one where both sides form consensus on long-term value and jointly advance on industrial resources, scenario judgment and key milestones.</p><p style="margin-bottom: 15px;"><strong>"If robots only have vision, they can only see the world; add touch, and they have the opportunity to truly manipulate the world."</strong></p><p style="margin-bottom: 15px;"><strong>"The two-way pursuit between entrepreneurs and investors is essentially a shared judgment of long-term value."</strong></p><p style="margin-bottom: 15px; text-align: right;"><strong>— Ma Daolin, Founder & CEO of Xense</strong></p><p style="margin-bottom: 15px;">At the Shanghai Youth Science and Innovation Carnival's Shanghai Jiao Tong University venue, Xense Robotics showcased tactile perception technologies and related product capabilities for embodied intelligence and precision manipulation.</p><p style="margin-bottom: 15px;">On site, the Xense team exchanged views with attending guests, young students and industry partners on robot tactile perception, multimodal perception, precision manipulation, intelligent inspection and industrial applications. During the event, relevant leaders and guests visited the Xense Robotics booth to learn about the company's technology progress in embodied touch, precision manipulation and intelligent inspection.</p><p style="margin-bottom: 15px;">Embodied intelligence is moving from technical demonstrations to industrial applications. For scenarios such as humanoid robots, precision manufacturing and intelligent inspection, the real difficulty is often not whether robots "can move," but whether they can complete tasks stably, reliably and reproducibly in complex physical contact. Tactile perception is precisely an important underlying capability for solving this problem.</p><p style="margin-bottom: 15px;">In the past few years, the robotics industry has focused more on vision, motion control and large model capabilities. But when robots enter real industrial sites, merely "seeing" is not enough. Robots need to know whether they have contacted the target, whether the grasp is stable, whether the force is appropriate, whether slip has occurred, and how to adjust next.</p><p style="margin-bottom: 15px;">This is also the reason Xense Robotics has long focused on embodied touch. The company builds robots' underlying capability to understand the real physical world around tactile hardware, data collection, model training and scenario implementation. Toward directions including humanoid robots, precision manufacturing and intelligent inspection, Xense hopes that through tactile technology, robots can move from "can move" to "usable and easy to use."</p><p style="margin-bottom: 15px;">Xense Robotics' development is also inseparable from the support of Shanghai's science and innovation ecosystem and Shanghai Jiao Tong University's achievement transformation environment.</p><p style="margin-bottom: 15px;">For hard-tech entrepreneurs, Shanghai's most important advantage is enabling technology to reach real industrial scenarios faster. Here there are university and research talents, a complete industrial chain, active capital, and a large number of application scenarios in intelligent manufacturing, robotics, automotive, precision manufacturing and more. For a young scientist startup team like Xense, Shanghai provides not just entrepreneurial space, but a complete soil from research to industrial implementation.</p><p style="margin-bottom: 15px;">The Y50 forum and the SJTU venue of the Shanghai Youth Science and Innovation Carnival further connect young entrepreneurs, investors, industry players and urban resources, giving more frontier technologies the opportunity to be seen, understood and moved toward real applications.</p><p style="margin-bottom: 15px;">From the CBN live broadcast studio to the Shanghai Jiao Tong University venue, Xense Robotics' appearance at Y50 was a concentrated expression of young scientist entrepreneurship, robot tactile technology and Shanghai's science and innovation ecosystem.</p><p style="margin-bottom: 15px;">In the future, Xense Robotics will continue to deepen the embodied touch direction, advancing robots from "seeing the world" toward "understanding and manipulating the real world," helping embodied intelligence land in more industrial scenarios.</p><p><br/></p>" "thumb" => "/storage/images/20260915/bb6b9103949a4d65540ca19b53555ccf.jpg" "auth" => "jsydl" "click" => 37 "edition" => 2 "keyword" => null "description" => "On May 10, the 7th Shanghai Youth Innovation and Entrepreneurship 50 Forum was held in Shanghai. This Y50, themed "Youth and City Growing Together," brought together young entrepreneurs, investors, universities, industry and urban resources, jointly presenting the innovative vitality of Shanghai's youth science and innovation ecosystem." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789450827 "update_time" => null "release_time" => 1778428800 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 35 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Xense Robotics CEO Ma Daolin Receives the 3rd Ruiyuan Young Scientist Award from Shanghai Jiao Tong University" "content" => "<p style="margin-bottom: 15px;">On April 6, on the occasion of the 130th anniversary of Shanghai Jiao Tong University, the 2026 Ruiyuan Science and Technology Award Ceremony and the SJTU Science Night were grandly held at Jingjing Hall on the Minhang campus. Xense Robotics founder and CEO Dr. Ma Daolin received the 3rd Ruiyuan Young Scientist Award.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789450646954533.jpg" title="1789450646954533.jpg" alt="2026-04-07-千觉机器人CEO马道林荣获上海交大第三届睿远青年科技奖.jpg"/></p><p style="margin-bottom: 15px;"><strong>130 Years of SJTU, Science and Innovation Crowned</strong></p><p style="margin-bottom: 15px;">The Ruiyuan Science and Technology Award was established in 2022 by SJTU alumnus Chen Guangming, founder of Ruiyuan Fund, together with his alma mater, to recognize SJTU people who have made outstanding contributions in basic research, applied research and frontier scientific exploration. This year's Science Night brought together academicians and experts from home and abroad, university leaders, faculty, students, alumni and guests from all walks of life.</p><p style="margin-bottom: 15px;">As the founder and chief scientist of Xense Robotics, Ma Daolin has always been committed to transforming frontier scientific research achievements into implementable industrial technologies, leading the team to break through core challenges in multimodal tactile perception and dexterous robot manipulation, helping robots truly "feel" the physical world.</p><p style="margin-bottom: 15px;"><strong>Deep Research, Entrepreneurial Original Aspiration</strong></p><p style="margin-bottom: 15px;">Dr. Ma Daolin is currently a professor and doctoral supervisor at the School of Naval Architecture, Ocean & Civil Engineering of Shanghai Jiao Tong University, with a PhD from Peking University and postdoctoral research experience at MIT. He has long conducted research around the core question of "how robots can perceive and manipulate dexterously like humans," overcoming multiple key technologies, with results published in top international journals and conferences, and has received the ICRA Best Paper Award.</p><p style="margin-bottom: 15px;">Based on long-term technical accumulation and research in dexterous robot manipulation and multimodal tactile perception, Ma Daolin founded Xense Robotics in 2024, translating years of academic accumulation into industry, dedicated to giving robots tactile and dexterous manipulation capabilities comparable to humans.</p><p style="margin-bottom: 15px;">In just two years since its founding, Xense Robotics has gained strong recognition from capital and the market. The company's cumulative financing exceeds RMB 100 million, with investors including Fucap Capital, Li Auto, Hillhouse Ventures, Oriza Holdings, Gobi Partners and other top institutions.</p><p style="margin-bottom: 15px;">At the same time, the company has received multiple authoritative certifications including Plug and Play China Global Open Innovation Top 100, Top 50 Most Concept-Validation-Capable Startup Companies, WRC China's TOP 30 Most Growth-Potential Robot Companies, and L'Oréal China BigBang Co-creation Program Winning Enterprise.</p><p style="margin-bottom: 15px;">To date, Xense technology has been implemented in embodied dexterous manipulation, industrial precision assembly, tactile inspection, flexible logistics and other fields, establishing deep cooperation with leading enterprises and research institutions including Google, AgiBot, Li Auto, SelfDrive and L'Oréal China.</p><p style="margin-bottom: 15px;">In the future, Xense Robotics will continue to ignite physical intelligence with touch, contributing to scientific and technological innovation.</p><p><br/></p>" "thumb" => "/storage/images/20260915/58883a2d5f909192ea8dcc7b1cb86abb.jpg" "auth" => "jsydl" "click" => 33 "edition" => 2 "keyword" => null "description" => "On April 6, on the occasion of the 130th anniversary of Shanghai Jiao Tong University, the 2026 Ruiyuan Science and Technology Award Ceremony and the SJTU Science Night were grandly held at Jingjing Hall on the Minhang campus. Xense Robotics founder and CEO Dr. Ma Daolin received the 3rd Ruiyuan Young Scientist Award." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789450663 "update_time" => 1789615971 "release_time" => 1775491200 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 34 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "OmniVTA Released, Powered by Xense Sensors! Visuo-Tactile World Model Solves Complex Contact Task Challenges" "content" => "<p style="margin-bottom: 15px;">In March 2026, the robotics academia witnessed a major breakthrough: the TARS Robotics Research Team, together with top institutions including the National University of Singapore, Fudan University, Clemson University and the Chinese Academy of Sciences, after 8 months of research, officially released OmniVTA — the world's first world model for visuo-tactile manipulation.</p><p style="margin-bottom: 15px;">The model open-sources a large-scale dataset OmniViTac containing 21,000+ records, covering 6 manipulation modes and 80+ tasks, and proposes a brand-new visuo-tactile manipulation framework, enabling robots to achieve a qualitative leap in performance on contact-based manipulation tasks.</p><p style="margin-bottom: 15px;">The core perception support behind this breakthrough research is precisely Xense Robotics' self-developed high-resolution multimodal visuo-tactile sensor. As the primary visuo-tactile perception hardware used in the research, the Xense sensor, with its core advantages of ultra-high precision, multimodal perception and industrial-grade reliability, provided OmniVTA with high-fidelity, high-timeliness visuo-tactile fusion data, becoming the key to cracking complex robot contact manipulation challenges.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789450163662230.jpg" title="1789450163662230.jpg" alt="2026-03-26-OmniVTA发布,千觉传感器助力!视触觉世界模型破解复杂接触任务难题.jpg"/></p><p style="margin-bottom: 15px;"><strong>Touch Is the "Last Mile" of Fine Manipulation</strong></p><p style="margin-bottom: 15px;">There is a long-standing pain point in robotics: "vision has limitations."</p><p style="margin-bottom: 15px;">In fine operations such as plugging in USB drives or adjusting test tubes, lighting changes, object occlusion and subtle mechanical changes at the moment of contact are all gaps that pure vision solutions cannot cross. The OmniVTA paper clearly states: "Contact-based manipulation tasks require precise perception of contact force, friction changes and state transitions, which cannot be reliably inferred by vision alone."</p><p style="margin-bottom: 15px;">This is precisely the meaning of Xense's existence: giving robots "human-like" tactile perception is the key to unlocking general manipulation capability for embodied intelligence.</p><p style="margin-bottom: 15px;">Xense Tactile Sensor: Providing OmniVTA with "Ultra-Sensitive" Fingertip Nerves</p><p style="margin-bottom: 15px;">In OmniVTA's data collection and model validation, the Xense sensor played the role of "source of data." Its core advantages became the "tactile data cornerstone" of OmniVTA's success.</p><p style="margin-bottom: 15px;"><strong>"Ultra-High-Resolution" Perception 800 Times Beyond Human Fingers</strong></p><p style="margin-bottom: 15px;">The Xense sensor has an information sensing density up to 800 times that of human fingers, capable of perceiving micrometer-level subtle features and deformations on object surfaces. In OmniVTA's assembly and wiping tasks, it is precisely this high resolution that allowed the model to capture the 3D shape distribution and subtle force changes at the moment of contact, training more accurate predictive models.</p><p style="margin-bottom: 15px;"><strong>True "Multimodal" Perception</strong></p><p style="margin-bottom: 15px;">The Xense sensor not only perceives pressure distribution, but can also decode 3D force distribution, six-axis resultant force and contact surface 3D shape in real time. While collecting underlying information including force, motion, slip and 3D surface morphology, it outputs multidimensional application data such as soft/hard discrimination, material recognition and contact state judgment, achieving deep fusion of "vision + touch." This is precisely the physical foundation for OmniVTA's "dual-stream world model" to accurately predict short-term contact evolution.</p><p style="margin-bottom: 15px;">In test tube handling and assembly tasks, the Xense sensor helps robots perceive the smoothness and fragility of objects in real time and precisely adjust grasping force. This delicate perception makes world-model-based predictions no longer just "guessing," but built on real physical interaction.</p><p style="margin-bottom: 15px;"><strong>Narrow Spaces and High-Speed Response: Making "Precision" and "Real-Time" Both Possible</strong></p><p style="margin-bottom: 15px;">The Xense sensor adopts a wedge design with a front end as thin as 5 mm, easily entering narrow areas and providing real-time tactile feedback within visual blind spots in precision assembly and other fine operations. Meanwhile, each frame of depth field processing requires only 10 ms of ultra-fast response, ensuring every contact change during the collection of 21,879 trajectories is precisely recorded, providing high-temporal-consistency quality data for model training.</p><p style="margin-bottom: 15px;">It is precisely the combination of "slim enough to enter" and "fast enough to keep up" that makes the Xense sensor a key support for OmniVTA's fine manipulation.</p><p style="margin-bottom: 15px;"><strong>From "Data Collection" to "World Model": Xense's Technology Foundation</strong></p><p style="margin-bottom: 15px;">OmniVTA's success is the product of high-quality data combined with powerful computing. Its open-source OmniViTac dataset contains 21,879 trajectories, 86 objects and 100+ tasks, covering 6 physical interaction modes: wiping, peeling, cutting, grasping, assembly and in-hand adjustment. In such a massive data collection project, the consistency, durability and data synchronization precision of tactile sensors are crucial.</p><p style="margin-bottom: 15px;"><strong>Xense not only provides hardware, but also builds a "foundation" at the data level:</strong></p><p style="margin-bottom: 15px;">High-precision synchronization: the sensor supports high-frequency data stream output, ensuring precise alignment of tactile and visual signals — a key premise for OmniVTA to achieve 60 Hz reflex control.</p><p style="margin-bottom: 15px;">Simulation tool collaboration: Xense_Sim, the world's first tactile simulation tool released in 2025, fills the technical gap in tangential force simulation, providing great convenience for OmniVTA team's algorithm validation and accelerating the 8-month research process.</p><p style="margin-bottom: 15px;"><strong>Toward the Future: Let the World Model "Feel" the Real World</strong></p><p style="margin-bottom: 15px;">OmniVTA validated an important path: predictive contact modeling + high-frequency tactile feedback = stable contact-based manipulation.</p><p style="margin-bottom: 15px;">This aligns perfectly with Xense's mission. As founder Ma Daolin said: "building spatial perception through touch and contact" is a brand-new path for robot manipulation.</p><p style="margin-bottom: 15px;">With the full open-sourcing of the OmniVTA dataset, embodied intelligence researchers worldwide will, for the first time, have access to such large-scale, high-quality real tactile interaction data. This is not only recognition of the Xense sensor's performance, but also a "tactile empowerment" for the entire industry.</p><p style="margin-bottom: 15px;">As a hardcore technology enterprise focused on multimodal tactile perception, we will continue to deepen sensor hardware, simulation tools and tactile algorithms. Because we believe that future general-purpose robots will need not only a pair of "sharp eyes," but also a pair of dexterous hands with "ultra-sensitive nerve endings."</p><p style="margin-bottom: 15px;"><br/></p><p style="margin-bottom: 15px;">Let robots truly "feel" and understand this world — that is what we are doing.</p><p style="margin-bottom: 15px;"><span style="color: rgb(127, 127, 127);">arXiv: https://arxiv.org/pdf/2603.19201</span></p><p style="margin-bottom: 15px;"><span style="color: rgb(127, 127, 127);">Project page: https://mrsecant.github.io/OmniVTA/</span></p><p style="margin-bottom: 15px;"><span style="color: rgb(127, 127, 127);">Dataset link: https://huggingface.co/datasets/tars-robotics/OmniVitac</span></p><p><br/></p>" "thumb" => "/storage/images/20260915/9d7303ef2e952f26b686c78b38e66256.jpg" "auth" => "jsydl" "click" => 37 "edition" => 2 "keyword" => null "description" => "In March 2026, the robotics academia witnessed a major breakthrough: the TARS Robotics Research Team, together with top institutions including the National University of Singapore, Fudan University, Clemson University and the Chinese Academy of Sciences, after 8 months of research, officially released OmniVTA — the world's first world model for visuo-tactile manipulation." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789450168 "update_time" => null "release_time" => 1774454400 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 33 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Vision + Touch | Xense Robotics, in Collaboration with Oxford, UCSD and Other Top Universities, Releases Visuo-Tactile Fusion Policy TouchGuide" "content" => "<p style="margin-bottom: 15px;">Does VTLA have to be trained from scratch? Combining touch with a state-of-the-art (SOTA) VLA model is a better approach.</p><p style="margin-bottom: 15px;">Recently, Xense Robotics, together with the University of Oxford, the University of California San Diego, Shanghai Jiao Tong University and Sun Yat-sen University, officially released two frontier research results in tactile sensing — TouchGuide and TacUMI. The papers are now available on arXiv, with project pages and code to be released progressively.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789449780863268.png" title="1789449780863268.png" alt="2026-02-12-视觉+触觉 _ 千觉联合牛津、UCSD等顶尖高校发布视触觉融合策略TouchGuide.png"/></p><p style="margin-bottom: 15px;"><strong>Vision tells us "looks good"; only touch can guarantee "really good."</strong></p><p style="margin-bottom: 15px;">In fine contact-rich manipulation, vision alone can only tell us which actions "look feasible," but true success often depends on the combined effect of vision and in-hand information (i.e., the contact information within the gripper provided by touch). TouchGuide's core idea is to give the policy access to touch at inference time, fusing what is "seen" with what is "felt" into the action space, and thereby pushing the action distribution toward real contact physics.</p><p style="margin-bottom: 15px;">TouchGuide does not retrain a new policy from scratch; instead, it provides "tactile guidance" to an existing vision-based policy at inference time. In terms of workflow, it first uses vision to generate a coarse action, then a task-relevant Contact Physics Model (CPM) produces a feasibility score that corrects and guides the action during sampling. The CPM is trained via contrastive learning on a small number of expert demonstrations, outputting a feasibility signal of "whether the action conforms to contact physics." As a result, it can be applied to diffusion policies and seamlessly integrated into flow-matching policies, enabling cross-policy tactile fusion.</p><p style="margin-bottom: 15px;">To validate this inference-time tactile guidance paradigm, the team designed five representative contact-intensive tasks: shoe-lacing (long-horizon, fine-grained task), chip transfer (dynamic interaction with fragile objects), cucumber peeling (continuous contact with dual-arm coordination), vase wiping (contact-dense manipulation), and lock picking under a low-data regime (only 20 demonstrations, requiring high precision). These tasks cover key challenges including complex contact, long horizons, force control with fragile objects, fine manipulation and low-demonstration learning.</p><p style="margin-bottom: 15px;">The results show that TouchGuide delivers consistent improvements across different base policies and different tactile modalities: for example, on π0.5, TouchGuide with tactile images achieves significantly higher average success rates than the vision-only baseline; it also brings clear gains on DP. More importantly, it reduces failures caused by "first contact," pulling actions back from regions that are visually plausible but physically infeasible in contact, and maintains strong generalization across different robots and different tactile modalities.</p><p style="margin-bottom: 15px;">High-quality tactile guidance presupposes multimodal data containing high-quality touch signals, so the team also released TacUMI: a low-cost, high-precision handheld multimodal tactile data collection system. TacUMI uses Vive Tracker and Lighthouse positioning to obtain accurate poses, delivers direct tactile feedback through a rigid fingertip interface, and synchronizes vision, touch and pose in a unified pipeline. Meanwhile, it keeps structural consistency between the collection end and the execution end, and can be quickly attached to different robot arms via adapters, closing the loop between "collectable data" and "usable policies."</p><p style="margin-bottom: 15px;">On the hardware design front, TacUMI is built around "direct tactile feedback": a rigid fingertip interface, Xense tactile sensors, magnetic encoders, a wrist camera and an onboard end-effector computing unit provide synchronized capture of high-resolution tactile images and force-field estimation. This minimal structure with unified interfaces makes high-precision tactile data acquisition lighter and more scalable.</p><p style="margin-bottom: 15px;"><br/></p><p style="margin-bottom: 15px;">For more details, please follow:</p><p style="margin-bottom: 15px;"><span style="color: rgb(127, 127, 127);">Project Page: https://martelzhang.github.io/touchguide/</span></p><p style="margin-bottom: 15px;"><span style="color: rgb(127, 127, 127);">GitHub: https://github.com/martelzhang/TouchGuide</span></p><p style="margin-bottom: 15px;"><span style="color: rgb(127, 127, 127);">arXiv: https://arxiv.org/abs/2601.20239</span></p><p><span style="color: rgb(127, 127, 127);">Source: https://mp.weixin.qq.com/s/XBequSE2rcLLOg2ALlYNwg</span></p><p><br/></p>" "thumb" => "/storage/images/20260915/6f04d2b5274d5440e6859b04c3318f0c.png" "auth" => "jsydl" "click" => 36 "edition" => 2 "keyword" => null "description" => "Does VTLA have to be trained from scratch? Combining touch with a state-of-the-art (SOTA) VLA model is a better approach." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789449796 "update_time" => null "release_time" => 1770825600 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 32 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => ""Scientists + Entrepreneurs" in the Spotlight at the Shanghai Two Sessions: Xense Robotics Founder Ma Daolin Featured as a Model of Science-to-Startup Innovation" "content" => "<p style="margin-bottom: 15px;">At this year's Shanghai Two Sessions, deputies and committee members held lively discussions around the exploration of cultivating "scientists + entrepreneurs" as set out in the draft outline of the city's 15th Five-Year Plan. Xense Robotics, headquartered in the Grand Zero Bay area of Minhang District, stands as a typical example of this model, and the entrepreneurial path of its founder, Ma Daolin — also a Professor at Shanghai Jiao Tong University — has attracted widespread attention.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789449524231672.png" title="1789449524231672.png" alt="2026-02-10-上海两会热议“科学家+创业者”,千觉机器人创始人马道林获聚焦:从实验室走出的科创典范.png"/></p><p style="margin-bottom: 15px;">Ding Xiaodong, a member of the Shanghai Committee of the Chinese People's Political Consultative Conference (CPPCC), noted that major scientific and technological innovation is becoming increasingly integrated with the market, and that enterprises have become key players in innovation. Founded by Ma Daolin in 2024, Xense Robotics is precisely a "research-driven enterprise" under this trend. The company focuses on the frontier field of multimodal tactile sensing, dedicated to translating high-precision sensing technology from the laboratory into physical products and solutions applied in intelligent manufacturing, advanced robotics and other industries.</p><p style="margin-bottom: 15px;">The successful transformation from scientist to entrepreneur owes much to the dual support of the regional innovation ecosystem and university-level institutional innovation. With the support of the "Grand Zero Bay One-Kilometer Incubator" and Shanghai Jiao Tong University's policies, the Xense team has been able to rapidly channel frontier tactile sensing technology toward industrial demand.</p><p style="margin-bottom: 15px;">Xense Robotics is by no means an isolated case, but it clearly marks out a path: built on world-class research, oriented by real demand, and supported by institutions and ecosystem, closing the loop from technological breakthrough to market value. Xense's practice demonstrates that when research depth meets market breadth in a well-functioning ecosystem, laboratory technology can cross barriers and grow into a core force driving industrial progress.</p><p style="margin-bottom: 15px;">Looking ahead, Xense Robotics will continue to deepen its work in tactile sensing technology, bring more innovative outcomes to market, and contribute to scientific and technological innovation and industrial upgrading.</p><p><br/></p>" "thumb" => "/storage/images/20260915/f221d50c9fa14d7fb27ea9ec0b44ee20.png" "auth" => "jsydl" "click" => 36 "edition" => 2 "keyword" => null "description" => "At this year's Shanghai Two Sessions, deputies and committee members held lively discussions around the exploration of cultivating "scientists + entrepreneurs" as set out in the draft outline of the city's 15th Five-Year Plan. Xense Robotics, headquartered in the Grand Zero Bay area of Minhang District, stands as a typical example of this model, and the entrepreneurial path of its founder, Ma Daolin — also a Professor at Shanghai Jiao Tong University — has attracte" "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789449526 "update_time" => 1789615813 "release_time" => 1770652800 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 31 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Xense Robotics Showcases at L'Oréal's Innovation Incubation Zone at the CIIE, Embarking on Tactile Technology Collaboration Exploration with L'Oréal China" "content" => "<p style="margin-bottom: 15px;">In the 2025 L'Oréal BIG BANG Beauty Tech Creation Program Challenge, Xense Robotics stood out with its leading multimodal tactile sensing technology. With the theme "Innovation Upgrade, Leading the Future," the challenge brought together the world's top innovative forces, and Xense Robotics distinguished itself among more than 700 participating enterprises to become a winner in the New Operations Leadership track.</p><p style="margin-bottom: 15px;"><img src="/file/ueditor/php/upload/image/20260915/1789441501674480.jpg" title="1789441501674480.jpg" alt="2025-11-11-千觉机器人亮相进博会欧莱雅创新孵化专区,与欧莱雅中国开启触觉技术合作探索-1.jpg"/></p><p style="margin-bottom: 15px;"><strong>L'Oréal North Asia BIG BANG Beauty Tech Creation Program Award</strong></p><p style="margin-bottom: 15px;">Xense's tactile solutions made a grand appearance with the L'Oréal Group at the Innovation Incubation Zone of the 8th China International Import Expo (CIIE), showcasing the new possibilities of tactile technology in beauty industry manufacturing.</p><p style="margin-bottom: 15px;"><strong>New Operations Leadership Track Winning Enterprise</strong></p><p style="margin-bottom: 15px;">Every shopping season, L'Oréal faces intense sorting and packaging pressure in e-commerce logistics. Staff must quickly and accurately pick samples from a vast number of SKUs — a process involving complex physical interactions. Humans accomplish this easily with dexterous hands and a sense of touch, but robots struggle because they lack real tactile perception.</p><p style="margin-bottom: 15px;">Xense Robotics' flexible sorting solution, built around tactile sensing technology, creatively breaks through the bottleneck of automated sample picking in traditional e-commerce logistics, enabling robots to precisely sense, flexibly grasp and manipulate a diverse range of beauty products.</p><p style="margin-bottom: 15px;">Xense Robotics will engage in a validation pilot (POC) collaboration with L'Oréal China, jointly exploring ways to enhance the agility and resilience of the supply chain.</p><p><br/></p>" "thumb" => "/storage/images/20260915/ac4f7371c634bd1a4d0ab69303fd35a5.jpg" "auth" => "jsydl" "click" => 34 "edition" => 2 "keyword" => null "description" => "In the 2025 L'Oréal BIG BANG Beauty Tech Creation Program Challenge, Xense Robotics stood out with its leading multimodal tactile sensing technology. With the theme "Innovation Upgrade, Leading the Future," the challenge brought together the world's top innovative forces, and Xense Robotics distinguished itself among more than 700 participating enterprises to become a winner in the New Operations Leadership track." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789441518 "update_time" => null "release_time" => 1762790400 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 30 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "IROS 2025 Comes to a Perfect Close | Xense Robotics Debuts New Products at Robotics Flagship Conference IROS 2025, Technical Strength Ignites On-Site Experience Craze" "content" => "<p style="margin-bottom: 15px;"><img src="https://xenserobotics.com/file/ueditor/php/upload/image/20260915/1789438815740438.png" title="1789438815740438.png" alt="2025-10-24-IROS2025 完美落幕 _ 千觉机器人携新品亮相机器人顶会IROS 2025,技术实力引爆现场体验热潮.png" style="text-wrap-mode: wrap;"/></p><p style="margin-bottom: 15px;">On October 24, 2025, IROS 2025 — one of the world's premier robotics conferences — came to a successful close at the Hangzhou International Expo Center. At this year's IROS, embodied intelligence, tactile sensing and fine manipulation, and human-robot interaction and collaboration emerged as the three most-watched frontier directions, fully reflecting the latest trends in global robotics research. As a globally leading tactile technology innovator, we are deeply inspired — touch has become a consensus topic in global research and a market trend, redefining how machines understand the world. At this exhibition, Xense Robotics presented its new intelligent tactile gripper, high-precision multimodal tactile sensors, and tactile autonomous decision-making manipulation scenarios. The technical strength in tactile sensing drew attention across the venue, and the booth remained packed with visitors throughout.</p><p style="margin-bottom: 15px;"><span style="font-size: 24px;"><strong>Exhibition site</strong></span></p><h1 style="margin-bottom: 15px;">01</h1><p style="margin-bottom: 15px;"><strong>Signature products make a stunning debut</strong></p><p style="margin-bottom: 15px;">As a highlight of this exhibition, Xense Robotics' intelligent tactile gripper was unveiled for the first time. Featuring a highly integrated design, the gripper embeds a self-developed high-precision visuo-tactile sensor and a 6 TOPS computing platform, enabling real-time local collection, processing and transmission of tactile data. It not only "perceives" but also "understands by touch" — capturing mechanical states, surface deformation and slip trends in real time, and achieving adaptive grasping and precise manipulation through deep fusion of perception and control. Combined with standardized interfaces and cross-platform compatibility, it delivers true plug-and-play, sense-and-control operation across research and industrial scenarios. Another star product that drew much attention — the high-precision multimodal tactile sensor — impressed visitors with a string of "industry-firsts."</p><h1 style="margin-bottom: 15px;">02</h1><p style="margin-bottom: 15px;"><strong>Live demos + hands-on experience</strong></p><p style="margin-bottom: 15px;">This year at IROS, the Xense booth was not only "technically strong" but also fully experiential. The interactive experience zone at the Xense booth became one of the most popular areas in the venue.</p><p style="margin-bottom: 15px;">Flexible insertion-extraction scenario: giving assembly a "sense of touch"</p><p style="margin-bottom: 15px;">In the industrial automation assembly demo, Xense showcased a flexible insertion-extraction system that deeply fuses high-precision tactile sensors with embodied intelligence algorithm frameworks. Facing standard components such as gears, USB, DVI and Ethernet ports, it perceives the "subtle signals" of contact just like a human hand — from "contact onset," to "change in force direction," to "insertion force distribution," the system perceives, analyzes and dynamically adjusts its actions in real time. Leveraging 0.06 mm-level deformation fields and millinewton-level force sensing precision, the robot completes insertion-extraction with high precision within 0.1–0.5 mm assembly clearances; dynamic force-position adjustment ensures no jamming and no damage, achieving true flexible assembly with self-correction.</p><p style="margin-bottom: 15px;"><strong>Technical highlights at a glance:</strong></p><p style="margin-bottom: 15px;">1. High-precision tactile-driven sub-millimeter assembly;</p><p style="margin-bottom: 15px;">2. Multimodal closed-loop control for real-time contact judgment and strategy switching;</p><p style="margin-bottom: 15px;">3. Self-learning algorithms reduce assembly errors and damage rates, significantly improving industrial reliability.</p><p style="margin-bottom: 15px;">Vase wiping task: letting robots understand "gentleness"</p><p style="margin-bottom: 15px;">In a home scenario, Xense's "vase wiping" demo amazed visitors. Facing the complex, fragile and reflective surface of a vase, the robot achieved compliant, safe and continuous wiping through deep fusion of touch and vision. It senses contact force and friction trends in real time, and performs dynamic force control and adaptive trajectory adjustment via embodied intelligence algorithms — easing off when force is too high, pressing in a bit more when force is too low, with every stroke precise and smooth, as if equipped with true "tactile nerves."</p><p style="margin-bottom: 15px;">1. Millinewton-level force control precision for fine wiping without damaging surfaces;</p><p style="margin-bottom: 15px;">2. Sensing curvature changes of irregular surfaces to adjust posture and applied force in real time;</p><p style="margin-bottom: 15px;">3. Tactile signals compensate for vision blind spots in reflective/occluded scenarios;</p><p style="margin-bottom: 15px;">4. Intelligent control based on friction trends ensures smooth and stable motions.</p><p style="margin-bottom: 15px;">Mahjong blind recognition: long queues at the interactive zone</p><p style="margin-bottom: 15px;">Using touch alone, the sensor accurately identifies mahjong tile textures, letting visitors personally experience the technical appeal of tactile perception. This novel interactive session not only became a photo-worthy hotspot at the booth, but also made abstract technical concepts intuitive and tangible.</p><h1 style="margin-bottom: 15px;">03</h1><p style="margin-bottom: 15px;"><strong>Technical strength earns international recognition</strong></p><p style="margin-bottom: 15px;">During the exhibition, the Xense Robotics booth hosted robotics experts, scholars, industry representatives and investors from around the world, engaging in in-depth exchanges on tactile sensing technology.</p><p style="margin-bottom: 15px;">In intelligent manipulation, the real challenge for machines is not "seeing" but "feeling." Traditional vision systems often "go blind" in complex environments with lighting, occlusion, reflection or deformation, and cannot handle the subtle friction, elastic changes and tiny pose errors that are hard for the naked eye to detect. The introduction of touch allows robots to judge "whether contact occurs," "contact direction" and "stability" at the moment of contact, enabling dual closed-loop control of force and pose, and thereby remaining stable and safe in complex physical interactions.</p><p style="margin-bottom: 15px;">More importantly, high-quality tactile data is becoming the key foundation driving embodied intelligence. Through multimodal fusion of touch and vision, robots no longer merely "execute commands" but gradually learn to "understand objects," "perceive the world" and "self-adjust" — this is the core direction of future embodied intelligence: moving robots from controllability toward perceivability and adaptability.</p><p style="margin-bottom: 15px;">With IROS 2025 drawing to a successful close, Xense Robotics validated its landing capabilities through outstanding tactile sensing technology and scenario demonstrations, showcasing China's breakthroughs and strength in core robotic perception and manipulation on the international stage.</p><p style="margin-bottom: 15px;">In the future, Xense will continue to deepen tactile technology, driving embodied intelligent agents from fine manipulation to general perception, from precise control to autonomous decision-making — from sensing, to understanding.</p><p><br/></p>" "thumb" => "/storage/images/20260915/40401889d7a586a57562a0a448c0e533.png" "auth" => "jsydl" "click" => 35 "edition" => 2 "keyword" => null "description" => "On October 24, 2025, IROS 2025 — one of the world's premier robotics conferences — came to a successful close at the Hangzhou International Expo Center. At this year's IROS, embodied intelligence, tactile sensing and fine manipulation, and human-robot interaction and collaboration emerged as the three most-watched frontier directions, fully reflecting the latest trends in global robotics research. As a globally leading tactile technology innovator, we are deeply inspired — touch has become a con" "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1789439052 "update_time" => null "release_time" => 1761235200 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 13 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "XENSE ROBOTICS Secures Pre-A Funding Round Backed by Top Market Institutions and Industrial Capital, Achieving A Total Funding Amount of Over 1 Hundred Million Yuan" "content" => "<p style="line-height: 2em; text-indent: 2em;">XENSE ROBOTICS (千觉机器人), a leading enterprise in embodied tactile intelligence, has successfully completed its Pre-A round of funding, achieving a total funding amount of over RMB 100 million. This marks the company's third funding round completed within the current year. <strong>This round was led by FT Capital(孚腾资本) (Shanghai Embodied Intelligence Fund 上海具身智能基金)</strong>. Participating investors included strategic partner <strong>Li Auto</strong> (理想汽车), alongside notable market-oriented institutions such as <strong>BEFOR CAPITAL</strong> (彬复资本) and <strong>Capital for Science & Industry </strong>(科实资本). Existing shareholders, including <strong>GL Ventures </strong>(高瓴创投), <strong>Oriza Ventures </strong>(元禾原点), and <strong>Gobi Partners</strong> (戈壁创投), continued their investment support.</p><p><br/></p><p style="line-height: 2em; text-indent: 2em;">Founded in May 2024 and headquartered in Shanghai, <strong>XENSE ROBOTICS</strong> is a high-tech enterprise focused on intelligent agent dexterous manipulation, with multimodal tactile sensing technology at its core. The company is dedicated to innovating tactile perception, enabling intelligent agents to understand the real world and advancing embodied intelligence from fine manipulation towards general perception.</p><p style="line-height: 2em; text-indent: 2em;"> </p><p style="line-height: 2em; text-indent: 2em;">In less than a year and a half since its inception, XENSE ROBOTICS has garnered strong confidence and investment from numerous institutions, including GL Ventures, Plug and Play China (璞跃中国), Jiao Tong University Han Yuan Fund (交大菡源基金), Agibot (智元机器人), Oriza Ventures, Gobi Partners, and Xiaomiao Langcheng Capital (小苗朗程). The participation of FT Capital and Li Auto not only reflects the shared recognition of XENSE's prospects by state-backed investment institutions and industrial capital but also significantly aids the company's strategic development, accelerating the deployment and adoption of its tactile sensing technology in real-world industrial scenarios. Currently, XENSE ROBOTICS's products and solutions have been validated and applied in pioneering scenarios, including embodied dexterous manipulation, industrial precision assembly, tactile inspection, agile logistics, and home intelligent agents. The company's products have received affirmation from leading industry clients and formed close collaborations with partners such as Agibot, X Square Robot (自变量), Li Auto, L'Oréal China, Haier, and Google DeepMind. The new funding will accelerate the company's plans for technological R&D, product iteration, team expansion, and market development, further solidifying XENSE ROBOTICS's leading position in embodied intelligent tactile manipulation and perception.</p><p style="line-height: 2em; text-indent: 2em;"> </p><p style="line-height: 2em; text-indent: 2em;">From an industry and investment perspective, a consensus has formed: tactile sensing is the core factor enabling fine, compliant manipulation and imbuing embodied interactions with a sense of "presence" and "warmth". High-quality tactile data is undoubtedly the "strategic mineral" that determines the performance ceiling of embodied manipulation models. The entire process – from acquiring and processing high-precision, multimodal tactile data to enabling operational control – imposes extremely high demands on a company's comprehensive R&D strength, ability to understand and utilize tactile information, capacity to define and deliver products and solutions, and capability for multimodal fusion. XENSE ROBOTICS possesses precisely these core advantages. Focusing exclusively on the tactile domain, the company has established a complete technological pathway from high-precision multimodal tactile perception systems to intelligent control algorithms, representing a highly scarce capability within the embodied intelligence industry.</p><p style="line-height: 2em; text-indent: 2em;"> </p><p style="line-height: 2em; text-indent: 0em;"><span style="font-size: 18px;"><strong>Representative from FT Capital</strong></span></p><p style="line-height: 2em; text-indent: 2em;">"Physical intelligence represents the frontier and the most anticipated challenge in AI development, determining whether AI can truly enter the physical world. Therefore, data and intelligence for physical interaction are the key cornerstones of physical intelligence. XENSE ROBOTICS, with its core visuotactile perception technology, is dedicated to overcoming the challenges of perceiving and understanding physical interaction. It is currently the only company in the market capable of providing solutions that surpass the sensing capabilities of the human finger. Its multimodal, high-resolution, high-precision tactile perception enables robots to achieve precise and compliant control, allowing intelligent agents to interact autonomously and safely with humans, environments, machines, and other forms of life. Embodied intelligence is a key strategic direction for Shanghai. As a local Shanghai innovator starting from industrial embodiment, XENSE ROBOTICS provides core tactile perception and control modules for the embodied intelligence and humanoid robotics industries, developing a core technological system for comprehensive physical interaction of intelligent agents. Its clear and pragmatic path to technology commercialization gives us strong confidence in its future prospects."</p><p style="line-height: 2em; text-indent: 2em;"> </p><p style="line-height: 2em; text-indent: 0em;"><span style="font-size: 18px;"><strong>Chen Yu, Founding Partner, BEFOR CAPITAL</strong></span></p><p style="line-height: 2em; text-indent: 2em;">"The deployment of embodied intelligence requires robots to physically interact with the real world, where the scarce tactile modality provides a crucial new dimension for perception. Visuotactile solutions are currently the only tactile approach that can offer a greater number of tactile sensing units than the human finger, providing more accurate detail on physical properties such as hardness, texture, slip, and contact sensation. Although large-scale industrial deployment is currently limited by lifespan and cost issues, we see the technological breakthroughs and engineering deployment explorations made by the XENSE ROBOTICS team, led by Professor Ma, in the visuotactile field. We are confident and optimistic about the widespread adoption of visuotactile solutions."</p><p style="line-height: 2em; text-indent: 2em;"> </p><p style="line-height: 2em; text-indent: 0em;"><span style="font-size: 18px;"><strong>Wang Guanda, General Manager of Beijing Operations Center, Capital for Science & Industry</strong></span></p><p style="line-height: 2em; text-indent: 2em;">"Tactile perception capability directly impacts the effectiveness of interaction between the model world and the physical world and is one of the key technological bottlenecks for implementing embodied intelligence scenarios. XENSE ROBOTICS, based on its visuotactile sensors, can provide multimodal, high-precision physical information about contact surfaces, such as 3D force field distribution and tactile images, meeting diverse client needs ranging from motion control to model training. The company's founder was a core member of the pioneering MIT team internationally researching the combined application of tactile sensing and fine robotic control; his theoretical research on external contact perception has been recognized at top international conferences. The company has now completed the R&D of a series of visuotactile sensors compatible with various end-effector forms. It holds significant potential to break through current technological application limitations in multiple scenarios, representing a vast potential market."<br/><br/><strong><span style="font-size: 18px;">Project Lead, GL Ventures</span></strong></p><p style="line-height: 2em; text-indent: 2em;">"Embodied intelligence is the critical pathway for AI to move from the virtual to the physical world, and high-precision tactile sensing is the core enabler for robots to achieve fine, compliant manipulation. The XENSE ROBOTICS team represents top-tier strength in this field, having successfully established a complete technological pathway from high-precision multimodal visuotactile systems to intelligent control algorithms, possessing highly scarce technical value. As the lead investor in XENSE ROBOTICS's Angel round, we continue to be confident in the team's technical prowess and engineering execution capabilities. We believe XENSE ROBOTICS will accelerate the integration of cutting-edge tactile perception capabilities into industrial manufacturing and next-generation intelligent agents, leading to further breakthroughs in embodied intelligence."<br/><br/><span style="font-size: 18px;"><strong>Representative, Oriza Ventures</strong></span></p><p style="line-height: 2em; text-indent: 2em;">"The ultimate goal of embodied intelligence is to achieve human-level precision manipulation and real-time interaction, and high-precision tactile sensing is key to realizing this leap. Currently, due to complex application scenarios and extremely high technical requirements, obtaining stable and reliable tactile information and achieving complex, fine manipulation remain core industry challenges. Advanced tactile sensing technologies and solutions represent critical 'bottleneck technologies' urgently needing breakthroughs within China's embodied intelligence field. In this context, XENSE ROBOTICS, as a domestic pioneer in visuotactile perception technology, has successfully transitioned its technology from lab to product and is accelerating its commercialization. With the rapid development of the embodied intelligence industry, we believe that, leveraging its full-chain tactile technology accumulation and industry-leading product capabilities, XENSE ROBOTICS holds very broad market prospects."</p><p><br/></p><p style="line-height: 2em; text-indent: 0em;"><strong><span style="font-size: 18px;">Representative, Gobi Partners</span></strong></p><p style="line-height: 2em; text-indent: 2em;">"Tactile perception is the cornerstone of robot interaction with the physical world. The technology's maturity is still at an early stage, indicating immense development potential. XENSE ROBOTICS has achieved several key technological breakthroughs in the multimodal tactile perception field, and its commercial progress is also leading in the market. We believe that, with its experienced R&D team and profound technical expertise, XENSE ROBOTICS will continue to lead technological innovation in the field of tactile perception, driving the progress and development of the embodied intelligence industry."</p><p style="line-height: 2em; text-indent: 2em;"> </p><p style="line-height: 2em; text-indent: 0em;"><span style="font-size: 18px;"><strong>"Enabling robots to perceive the physical world" – Innovative enterprises like XENSE ROBOTICS are steadily turning this vision into reality.</strong></span></p>" "thumb" => "/storage/images/20251107/8496ca18c4fb7a6f7821a80b6716eb1a.jpg" "auth" => "admin" "click" => 208 "edition" => 2 "keyword" => null "description" => "XENSE ROBOTICS (千觉机器人), a leading enterprise in embodied tactile intelligence, has successfully completed its Pre-A round of funding, achieving a total funding amount of over RMB 100 million. This marks the company's third funding round completed within the current year. This round was led by FT Capital(孚腾资本) (Shanghai Embodied Intelligence Fund 上海具身智能基金). Participating investors included strategic partner Li Auto (理想汽车), alongside notable market-oriented institutions such as BEFOR CAPITAL (彬复资" "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1760966311 "update_time" => 1789611662 "release_time" => 1760889600 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [
  "id" => 8
  "class_id" => 387222
  "path" => "37222,387222"
  "name" => ""
  "title" => "Minister of Science and Technology Yin Hejun Recognizes Breakthroughs Achieved by XENSE ROBOTICS"
  "content" => "<p style="line-height: 1.75em;">Yin Hejun, Minister of Science and Technology and Secretary of the Leading Party Group of the Ministry, recently led a delegation to inspect XENSE ROBOTICS, and highly commended the company’s pioneering research and breakthrough achievements in high-performance multimodal tactile sensing.</p><p><br/></p><p><img src="/file/ueditor/php/upload/image/20250901/1756693377416921.jpg" title="1756693377416921.jpg" alt="1756693377416921.jpg" width="927" height="695" border="0" vspace="0" style="width: 927px; height: 695px;"/></p><p><br/></p><p style="line-height: 1.75em;">During a demonstration at XENSE ROBOTICS’s exhibition hall, Minister Yin received a comprehensive briefing on the company’s core technological advancements and industrialization progress in tactile sensing. Ma Daolin, Founder and CEO, presented the company’s development milestones and showcased its latest innovations: the “G1-WS2.0 High-Sensitivity Multimodal Tactile Sensor” and the “Intelligent Gripper System with Integrated Tactile Sensors”. These systems demonstrated exceptional multidimensional tactile perception, dynamic response capabilities, and real-time adaptive control precision.</p><p><br/></p><p><img src="/file/ueditor/php/upload/image/20250901/1756693429823011.jpg" title="1756693429823011.jpg" alt="1756693429823011.jpg" width="927" height="695" border="0" vspace="0" style="width: 927px; height: 695px;"/></p><p><br/></p><p style="line-height: 1.75em;">Following the demonstration, Minister Yin expressed high recognition for XENSE ROBOTICS’s achievements in fine tactile perception and intelligent manipulation, particularly noting that the sensors “surpass human tactile sensitivity.” He encouraged the company to deepen industry-academia-research-application integration, accelerate technology iteration and commercialization, and contribute to China’s high-quality development and intelligent upgrading of the robotics industry.</p><p><br/></p><p><img src="/file/ueditor/php/upload/image/20250901/1756693518397767.jpg" title="1756693518397767.jpg" alt="1756693518397767.jpg" width="927" height="695" border="0" vspace="0" style="width: 927px; height: 695px;"/></p><p><br/></p><p style="line-height: 1.75em;">As a pioneer in multimodal tactile perception and intelligent manipulation for precision operations, XENSE ROBOTICS provides cutting-edge solutions for scenarios including dexterous robotic manipulation, industrial precision assembly, flexible logistics, and smart consumer products. Its technology bridges a critical gap in embodied robots’ physical interaction capabilities, ushering in a new era of intelligent physical perception and manipulation. The Ministry’s endorsement reinforces XENSE ROBOTICS’s commitment to overcoming core perception bottlenecks and leading embodied intelligence innovation.</p><p><br/></p><p style="line-height: 1.75em;">Since its July launch, XENSE ROBOTICS’s next-generation G1 Series Multimodal Tactile Sensors have received significant market acclaim. At WAIC 2025, XENSE ROBOTICSjoined seven other pioneers (including Agibot and Unitree Robotics) in the National Embodied Robotics Exhibition Zone, showcasing China’s advancements in embodied intelligence core technologies to Premier Li Qiang during his inspection tour.</p><p><br/></p>"
  "thumb" => "/storage/images/20251107/b66f37498a3d7be1d0883e992740dff3.jpg"
  "auth" => "jsydl"
  "click" => 183
  "edition" => 2
  "keyword" => null
  "description" => "Yin Hejun, Minister of Science and Technology and Secretary of the Leading Party Group of the Ministry, recently led a delegation to inspect XENSE ROBOTICS, and highly commended the company’s pioneering research and breakthrough achievements in high-performance multimodal tactile sensing. "
  "is_index" => 1
  "cover" => 0
  "status" => 1
  "sort" => 1
  "create_time" => 1756302642
  "update_time" => 1767681208
  "release_time" => 1756302642
  "delete_time" => null
  "mcontent" => ""
  "TTT" => ""
  "DDD" => ""
  "KKK" => ""
  "zdyfwb" => null
  "url" => ""
  "link" => ""
  "open_link" => 0
]
array:28 [ "id" => 9 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "XENSE ROBOTICS Invites You to FAIR plus 2025: Precision Tactile, Future Unlocked!" "content" => "<p style="line-height: 1.75em;">XENSE ROBOTICS to Showcase Multimodal Tactile Tech at FAIR plus 2025 Shenzhen Convention & Exhibition Center (Futian) | Booth H8C24 | April 24-26, 2025 Join us to experience how tactile technology redefines the boundaries of robot-physical world interaction.</p><p><br/></p><p style="text-align: center;"><strong><span style="font-size: 24px;">XENSE ROBOTICS</span></strong></p><section><section><section><section><section><section><section><section><section style="text-align: center;"><p><br/></p><p style="text-align: left;"><strong><span style="font-size: 20px;">XENSE ROBOTICS to Booth:H8C24</span></strong></p><p><br/></p><p style="text-align: left; line-height: 1.75em;">Xense Robotics, founded in May 2024 and headquartered in Shanghai, is a high-tech enterprise specializing in multimodal tactile sensing technology. The company is dedicated to advancing robotic fine manipulation through innovative tactile perception capabilities, providing core technological support for developing new quality productive forces in intelligent robotics.</p><p style="text-align: left; line-height: 1.75em;">Professor Ma Daolin, the founder, is a leading scientist in tactile perception. Currently serving as a Professor at Shanghai Jiao Tong University, he was awarded the Best Paper Award at ICRA 2021 (IEEE International Conference on Robotics and Automation) and pioneered the novel robotics approach of "building spatial perception through tactile sensing". The core team members hail from top-tier institutions worldwide, including MIT, Peking University, Shanghai Jiao Tong University, University College London, University of Sydney, etc. Xense Robotics possesses three core technologies: tactile sensors, tactile perception algorithms, and tactile control algorithms.</p><p style="text-align: left;"><br/></p><p><br/></p><section style="display: inline-block;vertical-align: bottom;width: auto;align-self: flex-end;flex: 0 0 auto;min-width: 5%;max-width: 100%;height: auto;margin: 0px -21px;padding: 5px 14px;box-sizing: border-box;"><section><p><span style="color: rgb(0, 0, 0);"><strong><span style="font-size: 24px;">CORE TECHNOLOGY AND PRODUCTS</span></strong></span></p></section></section><p><br/></p></section></section></section></section><section><section><section><section><p><br/></p><p style="text-align: left;">Xense Robotics specializes in developing multimodal tactile perception and intelligent control technologies for robotic fine manipulation, overcoming limitations of conventional tactile sensors that only detect pressure distribution with insufficient resolution. The company's proprietary multimodal tactile sensor delivers breakthrough innovation by simultaneously capturing high-resolution 3D force, kinesthetic, and slip perception data; achieving real-time high-precision motion tracking via tactile perception; and, pioneering the "External Contact Perception" theoretical framework, which enables robots to simultaneously perceive force and motion dynamics, providing a groundbreaking solution for dexterous operations.</p><p style="text-align: left;"><br/></p><p style="text-align: left; line-height: 1.75em;">Core products include:\u{200C} • High-Resolution Multimodal Tactile Sensors \u{200C}• Intelligent Tactile Perception & Control Modules</p><p style="text-align: left; line-height: 1.75em;"><br/></p><p><br/></p><section><section><p style="text-align: center;"><strong><span style="font-size: 24px;">APPLICATIONS</span></strong></p><p><br/></p><p style="line-height: 1.75em;">Humanoid robot dexterous hands, precision assembly, healthcare rehabilitation, warehouse logistics, etc.</p><p><br/></p><p style="text-align:center"><img src="/file/ueditor/php/upload/image/20250901/1756695058175098.jpg" title="1756695058175098.jpg" alt="1756695058175098.jpg" width="750" height="2056" border="0" vspace="0" style="width: 750px; height: 2056px;"/></p></section></section><p><br/></p></section></section></section></section></section></section></section></section></section><p><br/></p>" "thumb" => "/storage/images/20251107/75882779a7fea80d3dd163a9e724cdbe.jpg" "auth" => "jsydl" "click" => 145 "edition" => 2 "keyword" => null "description" => """ XENSE ROBOTICS to Showcase Multimodal Tactile Tech at FAIR plus 2025\n Shenzhen Convention & Exhibition Center (Futian) | Booth H8C24 | April 24-26, 2025\n Join us to experience how tactile technology redefines the boundaries of robot-physical world interaction. """ "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1756302748 "update_time" => 1789616251 "release_time" => 1744884000 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
array:28 [ "id" => 12 "class_id" => 387222 "path" => "37222,387222" "name" => "" "title" => "Empowers Dexterous Robotic Manipulation with Multimodal Tactile Perception Technology, Xense Robotics Completes Angel Round Funding" "content" => "<p style="line-height: 1.75em;">XENSE ROBOTICS, a company specializing in multimodal tactile perception technology, recently secured tens of millions of yuan in its angel round funding. GL Ventures (高瓴创投) led the round, with participation from Plug and Play China (璞跃中国), Jiao Tong University Hanyuan Fund (交大菡源基金), and other investors. The funds will be used for product R&D, business expansion, talent recruitment to propel the company's growth.</p><p><br/></p><section><p style="line-height: 1.75em;">Founded in May 2024 and headquartered in Shanghai, XENSE ROBOTICS specializes in developing multimodal tactile perception and intelligent control technologies for fine robotic manipulation. As humanoid robot industrial layout and development accelerates, tactile perception is emerging as a critical differentiating technology for next-generation robotics systems.</p><p><br/></p><p style="line-height: 1.75em;">Addressing the limitations of conventional tactile sensors—which detect only pressure distribution with insufficient resolution—XENSE ROBOTICS’s proprietary sensors provide high-resolution multimodal tactile data including 3D force, kinesthetic, and slip perception. This enables new tactile capabilities for next-generation humanoid robots to autonomously interact with physical environments and overcome dexterous manipulation bottlenecks. Currently, XENSE ROBOTICS’s products include high-resolution multimodal tactile sensors and intelligent tactile perception & control modules.</p><p><br/></p><p style="line-height: 1.75em;">Dr.Ma Daolin, Founder of XENSE ROBOTICS, is recognized as one of the most technically accomplished scientists in tactile perception. Globally, top talent in visuotactile research primarily originates from MIT’s Gelsight/Gelslim labs; Dr.Ma is among the few returnee entrepreneurs in this field. He earned his B.S. in Theoretical and Applied Mechanics from Peking University in 2009 and a Ph.D. from the same institution in 2015. After postdoctoral research at MIT’s Mcube Lab, he continued pioneering work in robotic manipulation and tactile perception. In 2021, Dr. Ma joined Shanghai Jiao Tong University and established the Laboratory for Operational Perception and Intelligence. He is now a Professor at the university.</p><p><br/></p><p style="line-height: 1.75em;">In tactile perception research, Dr.Ma proposed the novel concept of "building spatial perception through touch and contact" for robotic fine manipulation. In 2021, his study "Extrinsic Contact Sensing with Relative-Motion Tracking from Distributed Tactile Measurements" received the Best Conference Paper Award at ICRA, robotics’ most influential international conference.</p><p><br/></p><p style="line-height: 1.75em;">As a key scholar in 3D contact force field reconstruction, Dr.Ma achieved high-precision motion tracking via tactile sensing and pioneered the "Extrinsic Contact Sensing" theoretical framework. This breakthrough enables robots to simultaneously perceive "force" and "motion" during manipulation, laying the foundation for precise contact control in dexterous operations. While traditional sensors focus only on force measurement, Dr.Ma’s research demonstrates the value of "motion tracking" as a new tactile dimension—recognized as a pivotal advancement for tactile sensing technology.</p><p><br/></p></section><p><br/></p><section><p style="line-height: 1.75em;">Humanoid robots are emerging as new engines for technological competition and economic growth. XENSE ROBOTICS’s innovations in tactile perception will provide core technological support for developing new quality productive forces.</p><p><br/></p><p style="line-height: 1.75em;">"Dexterous manipulation is key to deploying general-purpose robots," according to Dr.Ma Daolin. "XENSE ROBOTICS is committed to empowering robotic dexterity through multimodal tactile perception, enabling robots to simulate human tactile sensitivity, finely perceive the physical world, and drive transformative advances that unlock intelligent robotics’ full productive potential." Currently, general robots represented by humanoid robots are becoming a new engine for technological competition and economic development, and XENSE ROBOTICS's innovations in the field of tactile perception will also provide core technical support for fostering new quality productivity.</p></section><p><br/></p><p><br/></p><p style="text-align: center;"><strong><span style="font-size: 20px;">Investor Perspectives</span></strong></p><p><br/></p><p><strong><span style="font-size: 18px;">Project Lead,GL Ventures</span></strong></p><p><br/></p><p style="line-height: 1.75em;">"Embodied intelligence is crucial for AI’s expansion into the physical world. Tactile perception—a core technology in this ecosystem—critically impacts autonomy, intelligence, and safety. Professor Ma’s team combines deep technical expertise with comprehensive industry vision. We’re confident they’ll deliver exceptional tactile solutions and create significant value for the embodied intelligence industry."</p><p><br/></p><p><strong><span style="font-size: 18px;">Zhu Xiaowen, Partner, Plug and Play China</span></strong></p><p><br/></p><p style="line-height: 1.75em;">"Tactile perception is vital for robotic end-effectors and serves as the ‘last mile’ technology connecting planning, execution, and perception. As an innovative data dimension, it accelerates end-to-end embodied AI training. We’re confident in Professor Ma’s team to rapidly deploy this technology across industrial robotics while advancing humanoid dexterity."</p><p><br/></p><p><strong><span style="font-size: 18px;">Jiao Tong University Han Yuan Fund Representative</span></strong></p><p><br/></p><p style="line-height: 1.75em;">"With its expertise in multimodal tactile perception, XENSE enables hand-eye coordinated precision manipulation. We foresee rapid commercialization across industrial scenarios, positioning this technology as a key driver of productive forces."</p><p><br/></p><p style="text-align:center"><img src="/file/ueditor/php/upload/image/20250901/1756695587902208.png" title="1756695587902208.png" alt="1756695587902208.png" width="400" height="131" border="0" vspace="0" style="width: 400px; height: 131px;"/></p><p><span style="font-size: 18px;"><strong>About XENSE ROBOTICS</strong></span></p><p><br/></p><p style="line-height: 1.75em;">Xense Robotics is committed to empowering robots with dexterous manipulation through multimodal tactile perception.</p><p style="line-height: 1.75em;"><br/></p><p style="line-height: 1.75em;">Xense Robotics focuses on researching and developing multimodal tactile perception and intelligent technologies for robot fine manipulation. Related products include high-resolution multimodal tactile sensors, tactile perception and control intelligent modules, etc. These sensors provide multimodal tactile perception information, such as high-resolution three-dimensional force sensation, kinesthetic sensation, and slip sensation, solving the limitations of traditional sensors that only detect pressure distribution and lack sufficient spatial resolution. This innovation offers new tactile perception capabilities for the next generation of humanoid robots to achieve autonomous interaction with the physical environment, empowering them to overcome dexterous manipulation bottlenecks and providing core technical support for the new quality productivity of intelligent robots.</p><p style="line-height: 1.75em;"><br/></p><p style="line-height: 1.75em;">Founded in 2024 and headquartered in Shanghai, Xense Robotics has a founding team from top universities worldwide, with deep expertise and leadership in the field. Leveraging top-tier technical capabilities, aiming to deliver optimal solutions for tactile perception. Currently, Xense Robotics has secured investments from leading venture capital firms, including GL Ventures.</p><p><br/></p>" "thumb" => "/storage/images/20251107/cfe22d9b175a0aac191b60047405eb10.jpg" "auth" => "jsydl" "click" => 176 "edition" => 2 "keyword" => null "description" => "XENSE ROBOTICS, a company specializing in multimodal tactile perception technology, recently secured tens of millions of yuan in its angel round funding. GL Ventures (高瓴创投) led the round, with participation from Plug and Play China (璞跃中国), Jiao Tong University Hanyuan Fund (交大菡源基金), and other investors. The funds will be used for product R&D, business expansion, talent recruitment to propel the company's growth." "is_index" => 1 "cover" => 0 "status" => 1 "sort" => 1 "create_time" => 1756695647 "update_time" => 1789615750 "release_time" => 1728656520 "delete_time" => null "mcontent" => "" "TTT" => "" "DDD" => "" "KKK" => "" "zdyfwb" => null "url" => "" "link" => "" "open_link" => 0 ]
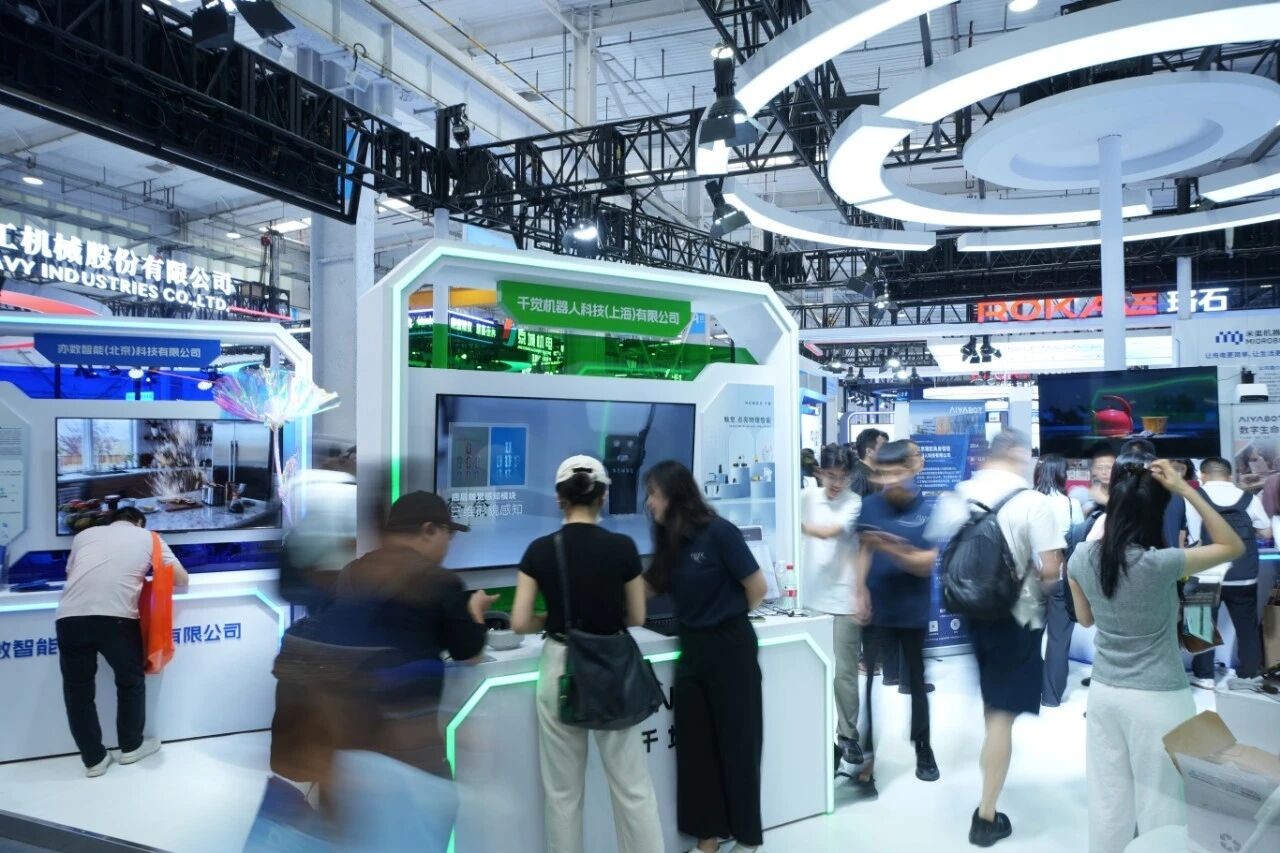
WRC 2026 in Progress | Xense Tactile Perception Capabilities Continue to Evolve
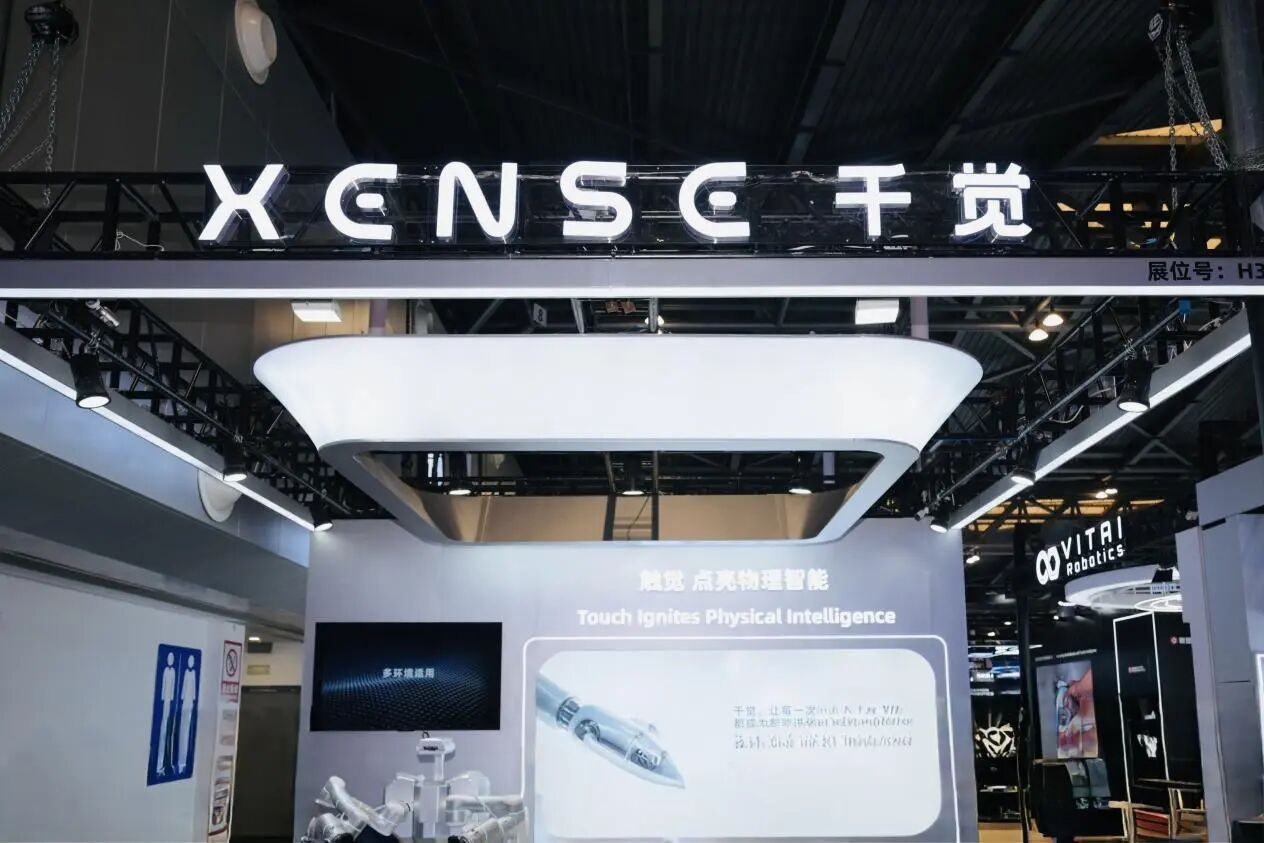
Tactile-Native Breakthrough for Embodied Intelligence | Xense Robotics Builds a Full-Stack Tactile Ecosystem at WAIC 2026
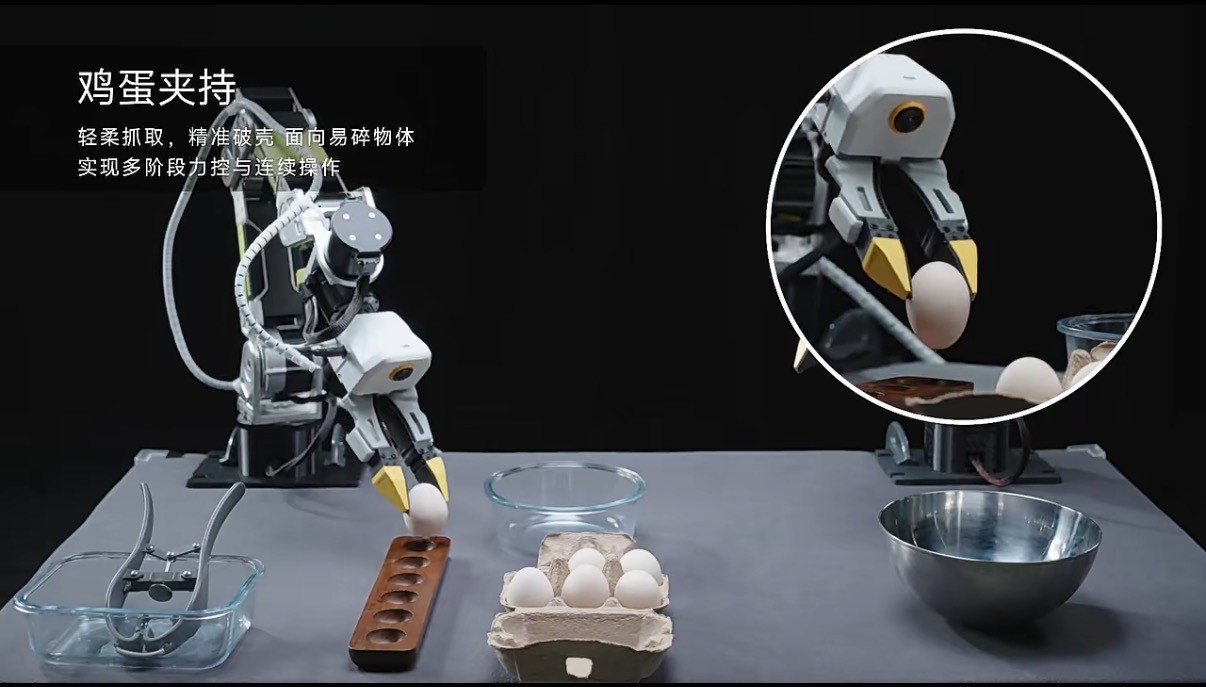
Major Release | Xense Robotics Launches the First VTLA Embodied Tactile Model X-TouchMind V1 and the First Visuo-Tactile Multimodal Dataset TacVerse 1k
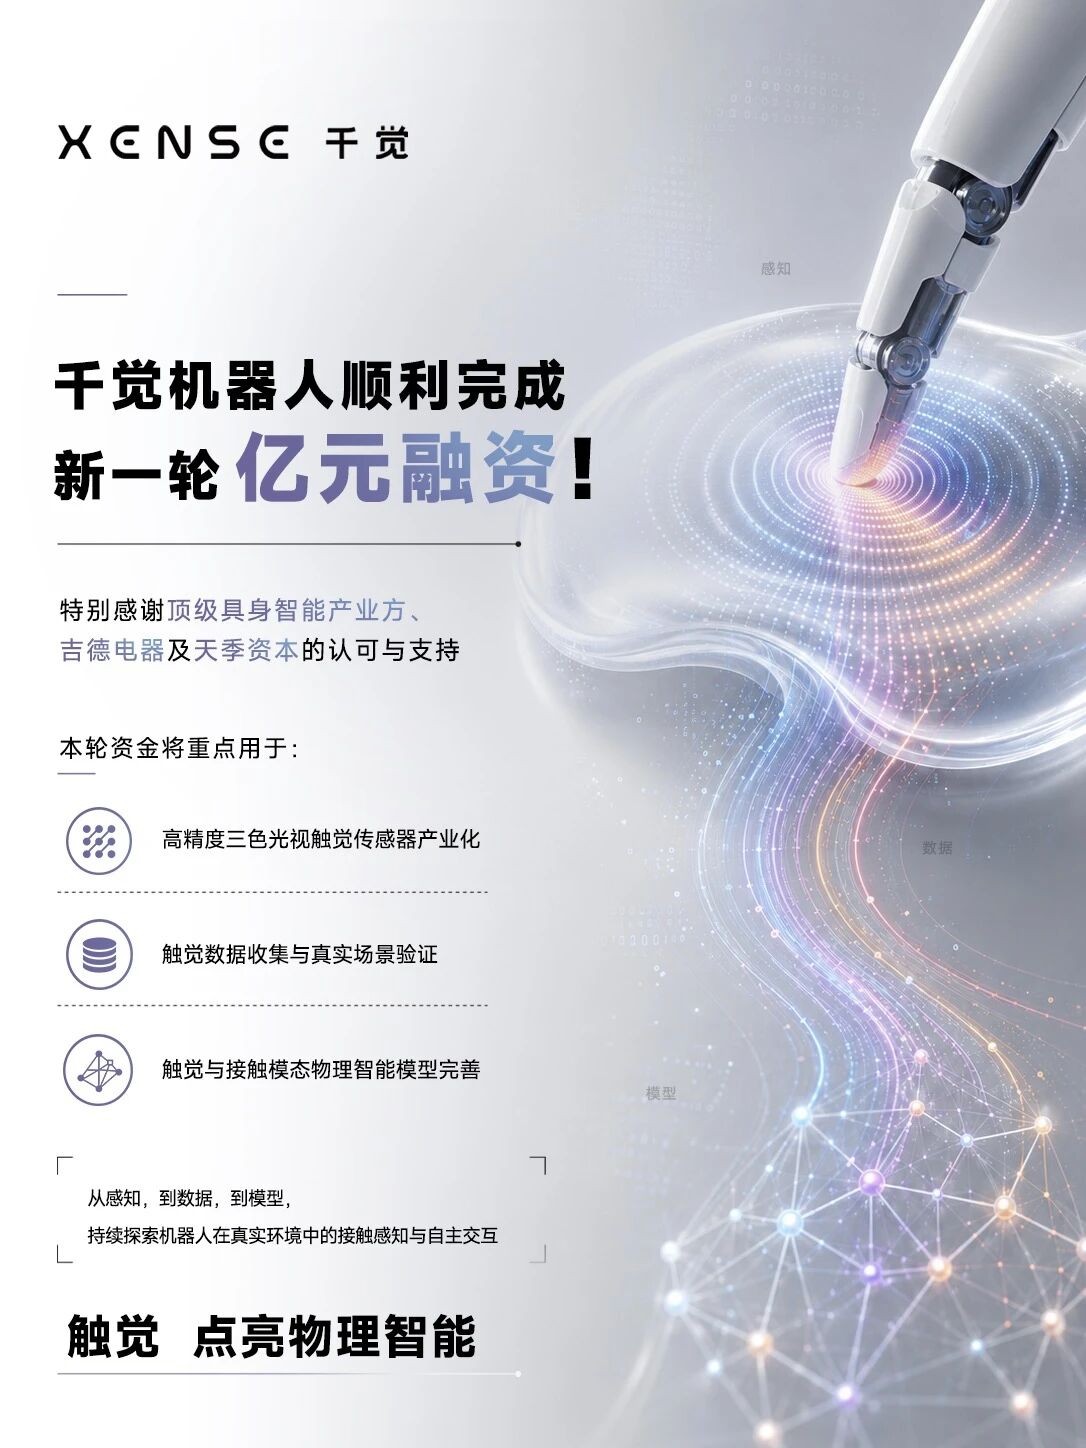
Xense Robotics Completes Hundred-Million-RMB Financing, Accelerating Tactile Perception, Data and Model System Implementation
Xense Named a WEF Technology Pioneer | Defining the Future Path of Embodied Intelligence with Tactile Foresight
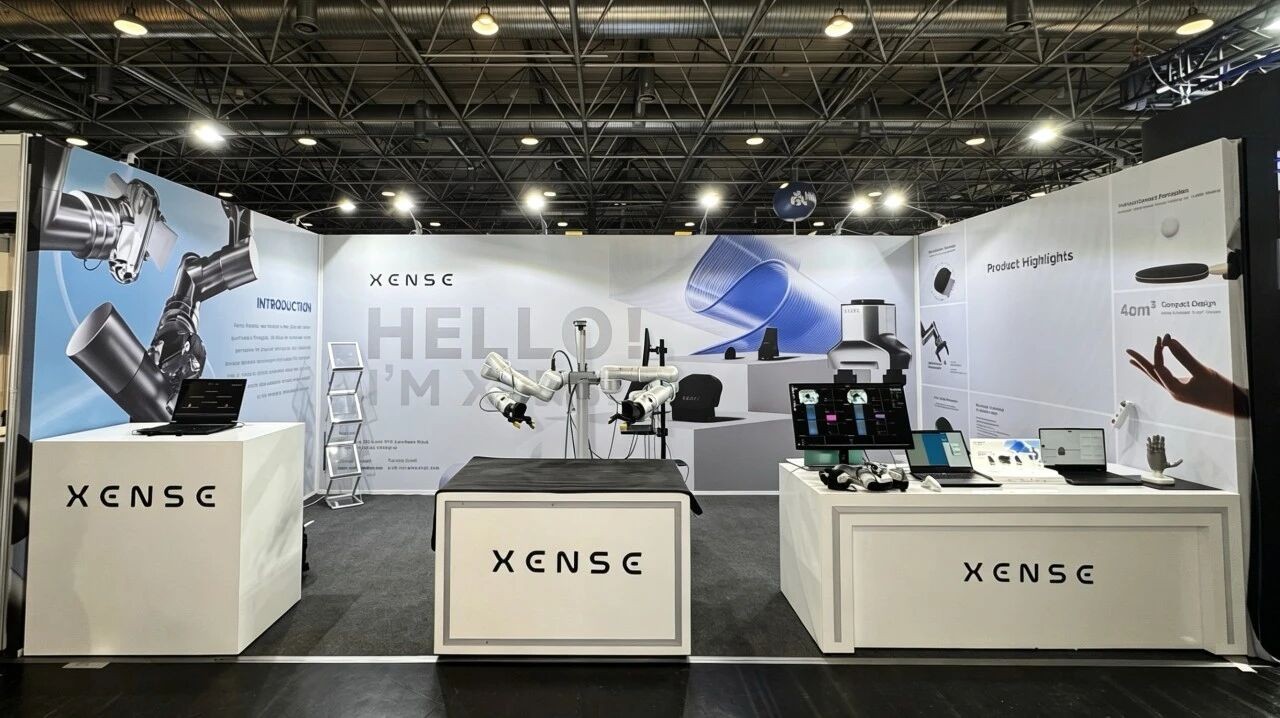
Touch Ignites Physical Intelligence! Xense Showcases the VTLA Model and Tactile Data Collection Devices at ICRA 2026, Demonstrating Hardcore Strength
Xense Robotics at ICRA 2026 Workshop: For Real-World Manipulation, Robots Need a "Tactile Foundation"
Xense Robotics at the 7th Y50 Forum: Showcasing the Power of Youth Hard-Tech Entrepreneurship Through Tactile Perception
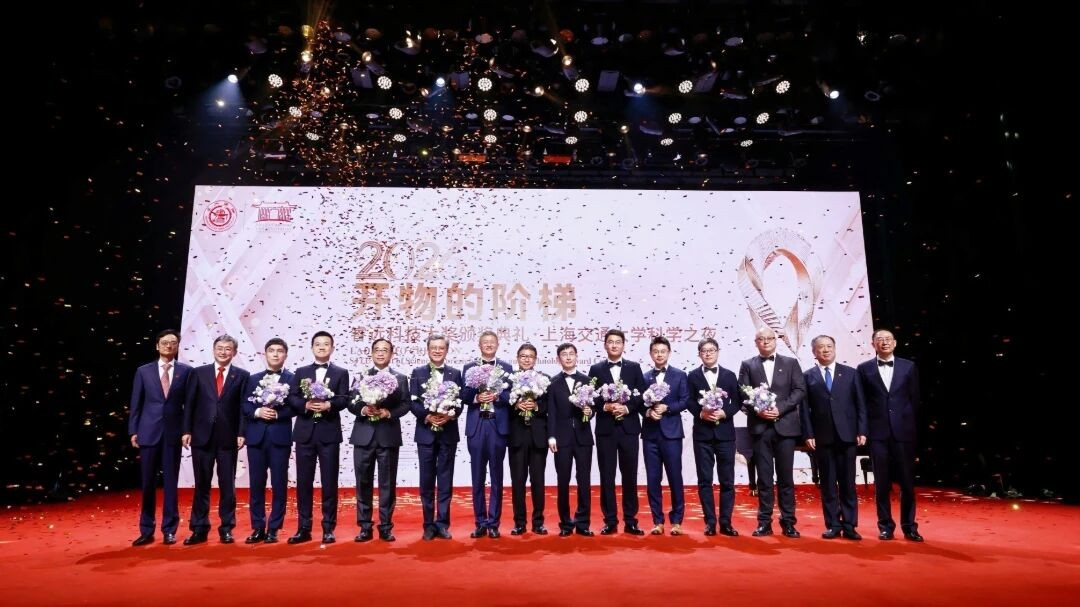
Xense Robotics CEO Ma Daolin Receives the 3rd Ruiyuan Young Scientist Award from Shanghai Jiao Tong University
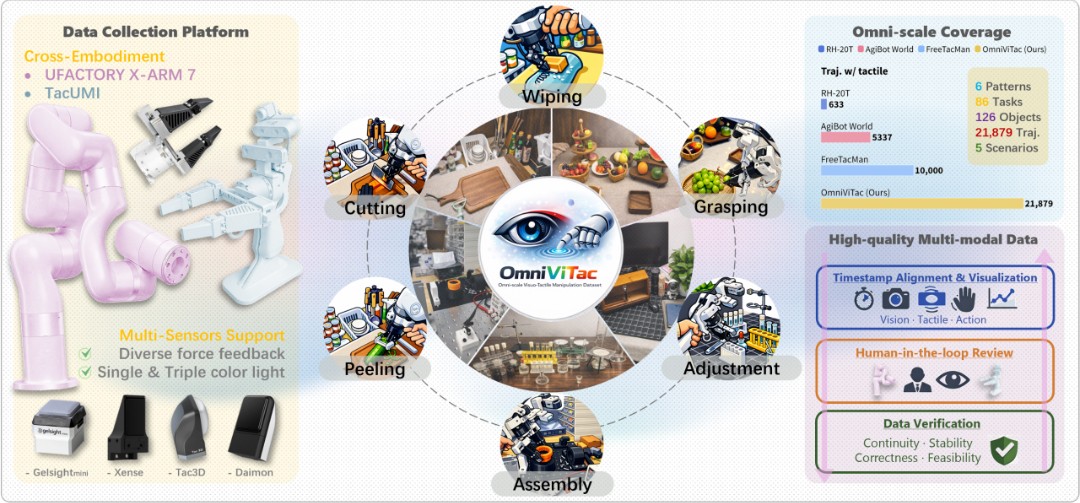
OmniVTA Released, Powered by Xense Sensors! Visuo-Tactile World Model Solves Complex Contact Task Challenges
Vision + Touch | Xense Robotics, in Collaboration with Oxford, UCSD and Other Top Universities, Releases Visuo-Tactile Fusion Policy TouchGuide
"Scientists + Entrepreneurs" in the Spotlight at the Shanghai Two Sessions: Xense Robotics Founder Ma Daolin Featured as a Model of Science-to-Startup Innovation
Xense Robotics Showcases at L'Oréal's Innovation Incubation Zone at the CIIE, Embarking on Tactile Technology Collaboration Exploration with L'Oréal China
IROS 2025 Comes to a Perfect Close | Xense Robotics Debuts New Products at Robotics Flagship Conference IROS 2025, Technical Strength Ignites On-Site Experience Craze

XENSE ROBOTICS Secures Pre-A Funding Round Backed by Top Market Institutions and Industrial Capital, Achieving A Total Funding Amount of Over 1 Hundred Million Yuan

Minister of Science and Technology Yin Hejun Recognizes Breakthroughs Achieved by XENSE ROBOTICS

XENSE ROBOTICS Invites You to FAIR plus 2025: Precision Tactile, Future Unlocked!

Empowers Dexterous Robotic Manipulation with Multimodal Tactile Perception Technology, Xense Robotics Completes Angel Round Funding
Scan the QR code to Purchase

