Summary
In March 2026, the robotics academia witnessed a major breakthrough: the TARS Robotics Research Team, together with to…
In March 2026, the robotics academia witnessed a major breakthrough: the TARS Robotics Research Team, together with top institutions including the National University of Singapore, Fudan University, Clemson University and the Chinese Academy of Sciences, after 8 months of research, officially released OmniVTA — the world's first world model for visuo-tactile manipulation.
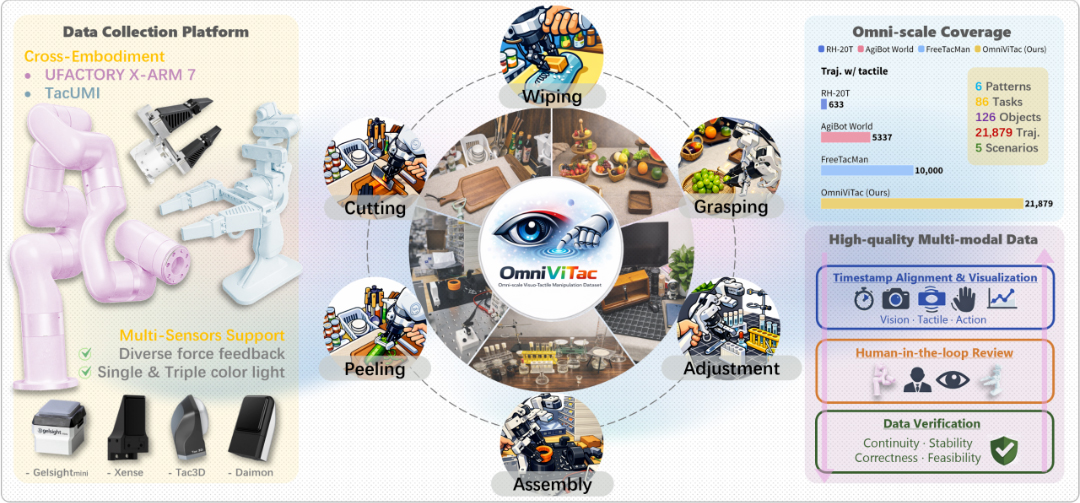
The model open-sources a large-scale dataset OmniViTac containing 21,000+ records, covering 6 manipulation modes and 80+ tasks, and proposes a brand-new visuo-tactile manipulation framework, enabling robots to achieve a qualitative leap in performance on contact-based manipulation tasks.
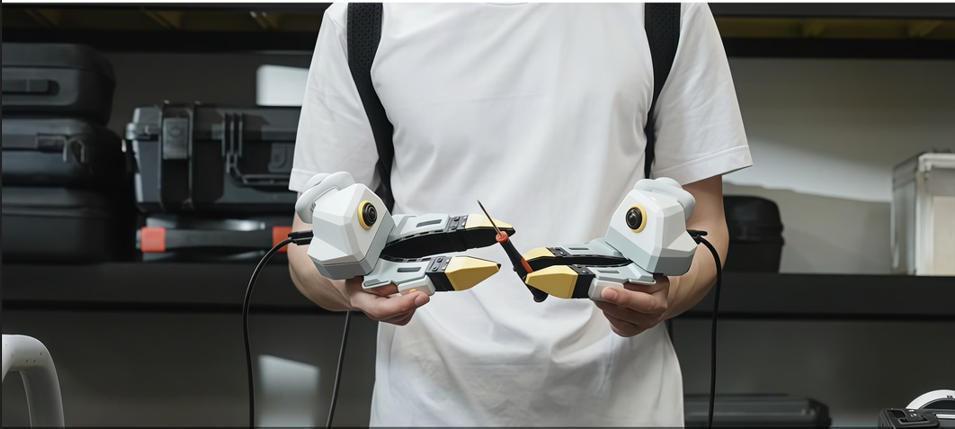
The core perception support behind this breakthrough research is precisely Xense Robotics' self-developed high-resolution multimodal visuo-tactile sensor. As the primary visuo-tactile perception hardware used in the research, the Xense sensor, with its core advantages of ultra-high precision, multimodal perception and industrial-grade reliability, provided OmniVTA with high-fidelity, high-timeliness visuo-tactile fusion data, becoming the key to cracking complex robot contact manipulation challenges.
Touch Is the "Last Mile" of Fine Manipulation
There is a long-standing pain point in robotics: "vision has limitations."
In fine operations such as plugging in USB drives or adjusting test tubes, lighting changes, object occlusion and subtle mechanical changes at the moment of contact are all gaps that pure vision solutions cannot cross. The OmniVTA paper clearly states: "Contact-based manipulation tasks require precise perception of contact force, friction changes and state transitions, which cannot be reliably inferred by vision alone."
This is precisely the meaning of Xense's existence: giving robots "human-like" tactile perception is the key to unlocking general manipulation capability for embodied intelligence.
Xense Tactile Sensor: Providing OmniVTA with "Ultra-Sensitive" Fingertip Nerves
In OmniVTA's data collection and model validation, the Xense sensor played the role of "source of data." Its core advantages became the "tactile data cornerstone" of OmniVTA's success.
"Ultra-High-Resolution" Perception 800 Times Beyond Human Fingers
The Xense sensor has an information sensing density up to 800 times that of human fingers, capable of perceiving micrometer-level subtle features and deformations on object surfaces. In OmniVTA's assembly and wiping tasks, it is precisely this high resolution that allowed the model to capture the 3D shape distribution and subtle force changes at the moment of contact, training more accurate predictive models.
True "Multimodal" Perception
The Xense sensor not only perceives pressure distribution, but can also decode 3D force distribution, six-axis resultant force and contact surface 3D shape in real time. While collecting underlying information including force, motion, slip and 3D surface morphology, it outputs multidimensional application data such as soft/hard discrimination, material recognition and contact state judgment, achieving deep fusion of "vision + touch." This is precisely the physical foundation for OmniVTA's "dual-stream world model" to accurately predict short-term contact evolution.
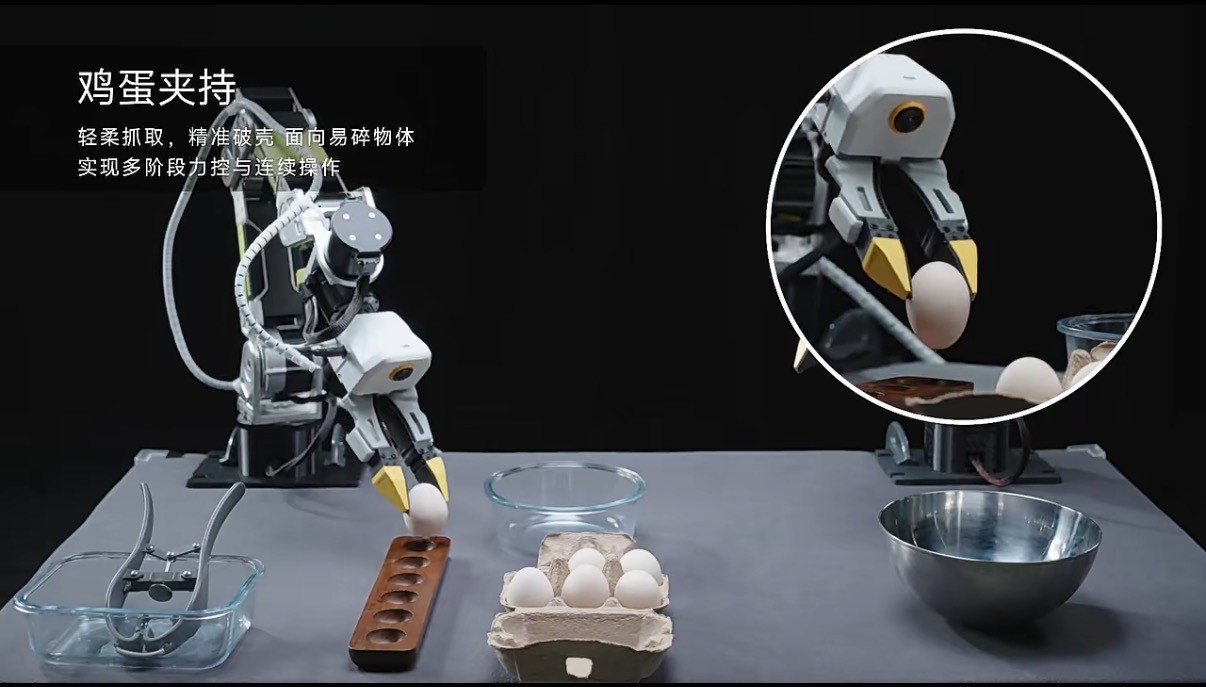
In test tube handling and assembly tasks, the Xense sensor helps robots perceive the smoothness and fragility of objects in real time and precisely adjust grasping force. This delicate perception makes world-model-based predictions no longer just "guessing," but built on real physical interaction.
Narrow Spaces and High-Speed Response: Making "Precision" and "Real-Time" Both Possible
The Xense sensor adopts a wedge design with a front end as thin as 5 mm, easily entering narrow areas and providing real-time tactile feedback within visual blind spots in precision assembly and other fine operations. Meanwhile, each frame of depth field processing requires only 10 ms of ultra-fast response, ensuring every contact change during the collection of 21,879 trajectories is precisely recorded, providing high-temporal-consistency quality data for model training.
It is precisely the combination of "slim enough to enter" and "fast enough to keep up" that makes the Xense sensor a key support for OmniVTA's fine manipulation.
From "Data Collection" to "World Model": Xense's Technology Foundation
OmniVTA's success is the product of high-quality data combined with powerful computing. Its open-source OmniViTac dataset contains 21,879 trajectories, 86 objects and 100+ tasks, covering 6 physical interaction modes: wiping, peeling, cutting, grasping, assembly and in-hand adjustment. In such a massive data collection project, the consistency, durability and data synchronization precision of tactile sensors are crucial.
Xense not only provides hardware, but also builds a "foundation" at the data level:
High-precision synchronization: the sensor supports high-frequency data stream output, ensuring precise alignment of tactile and visual signals — a key premise for OmniVTA to achieve 60 Hz reflex control.
Simulation tool collaboration: Xense_Sim, the world's first tactile simulation tool released in 2025, fills the technical gap in tangential force simulation, providing great convenience for OmniVTA team's algorithm validation and accelerating the 8-month research process.
Toward the Future: Let the World Model "Feel" the Real World
OmniVTA validated an important path: predictive contact modeling + high-frequency tactile feedback = stable contact-based manipulation.
This aligns perfectly with Xense's mission. As founder Ma Daolin said: "building spatial perception through touch and contact" is a brand-new path for robot manipulation.
With the full open-sourcing of the OmniVTA dataset, embodied intelligence researchers worldwide will, for the first time, have access to such large-scale, high-quality real tactile interaction data. This is not only recognition of the Xense sensor's performance, but also a "tactile empowerment" for the entire industry.
As a hardcore technology enterprise focused on multimodal tactile perception, we will continue to deepen sensor hardware, simulation tools and tactile algorithms. Because we believe that future general-purpose robots will need not only a pair of "sharp eyes," but also a pair of dexterous hands with "ultra-sensitive nerve endings."
Let robots truly "feel" and understand this world — that is what we are doing.
arXiv: https://arxiv.org/pdf/2603.19201
Project page: https://mrsecant.github.io/OmniVTA/
Dataset link: https://huggingface.co/datasets/tars-robotics/OmniVitac