Summary
On August 19, the 2026 World Robot Conference officially opened at Yizhuang, Beijing. On August 19, the 2026 World Rob…
On August 19, the 2026 World Robot Conference officially opened at Yizhuang, Beijing.
At this WRC, Xense Robotics appeared at booth A107, showcasing an integrated whole-hand tactile solution, the XTac UMI G1 wearable tactile data collection gripper, and interactive experiences with multimodal tactile sensors.
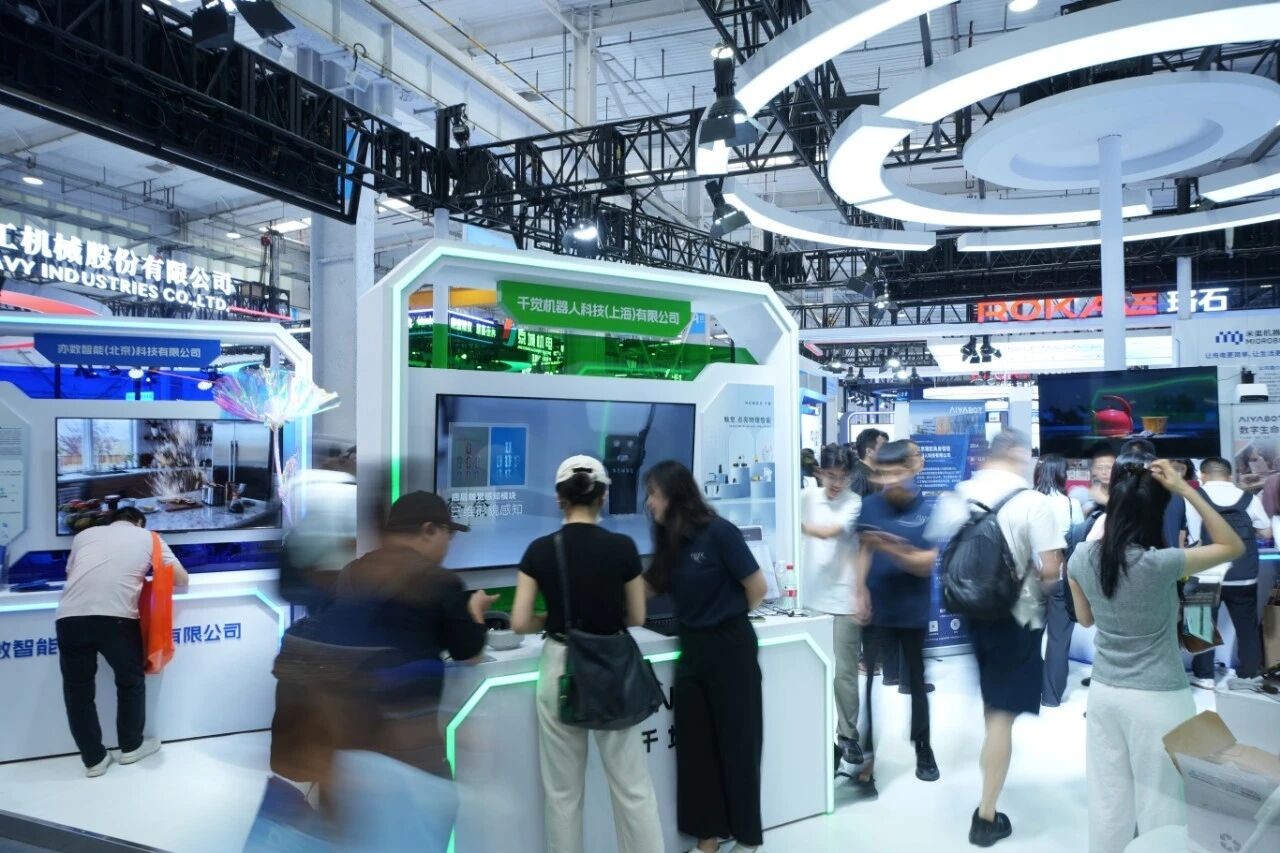
At the exhibition site, the Xense booth attracted many professional visitors. Through pressing and sliding operations, visitors could observe in real time the sensor's perception feedback of 3D deformation, force distribution and slip state, and experience the high-quality tactile data collection process through the lightweight wearable collection device.
Behind the lightweight hardware demonstration is Xense Robotics' technical path of continuously building a full-stack tactile ecosystem closed loop: starting from tactile hardware, connecting real interaction data, model training and scenario applications, so that touch goes beyond the sensor level and becomes the foundational capability for robots to understand and manipulate the physical world.
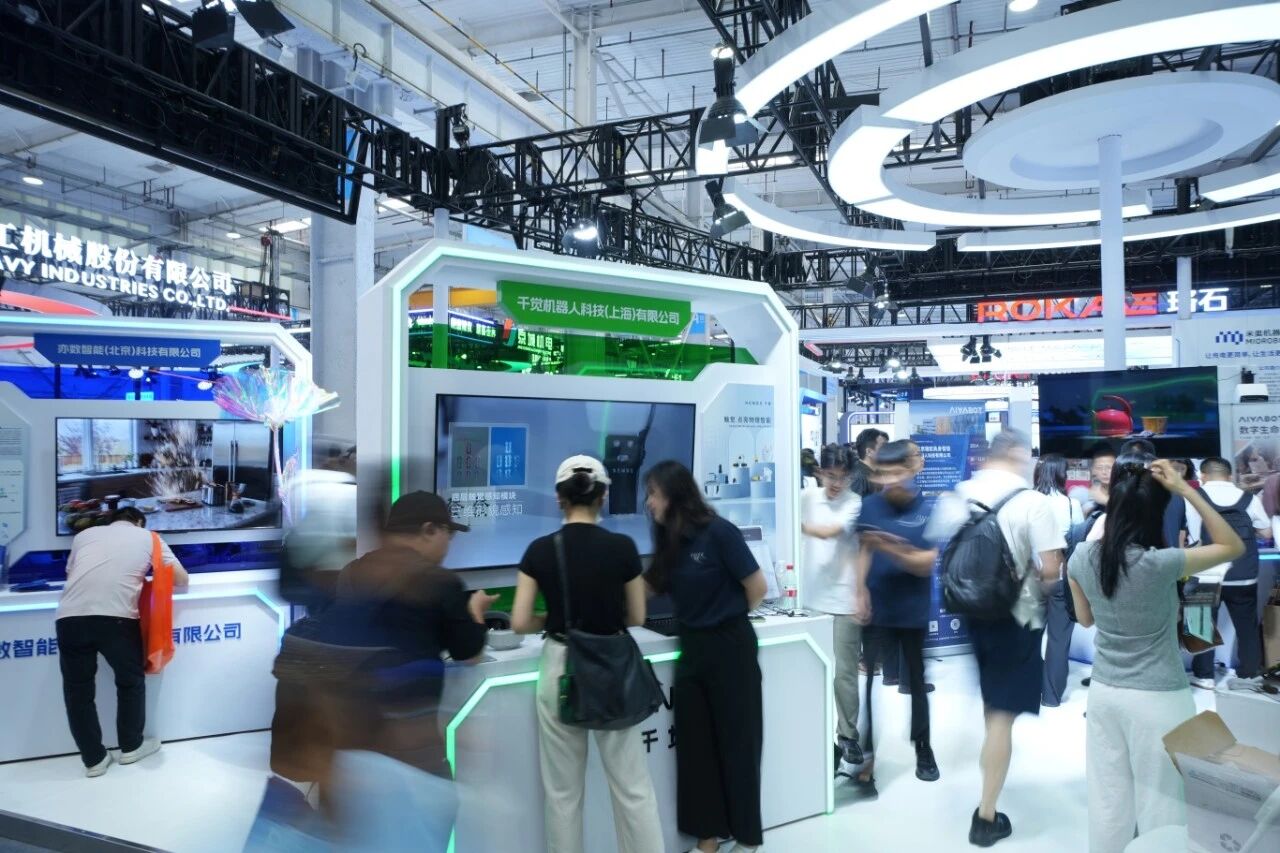
WRC Xense Exhibition Area
01 Whole-Hand Solution
Giving dexterous hands human-level tactile perception
This year, the industry's requirements for touch are undergoing a major shift: from "whether there is touch" to "whether there is high-quality touch suitable for dexterous hands." From fingertip to whole-hand tactile solutions, Xense's tactile perception capabilities are continuously evolving.
In real manipulation, touch does not only occur at a single point. The fine contact at the fingertip, the force perception in the palm area, and the coordinated feedback among different positions together determine the depth of a robot's understanding of an object. Xense's whole-hand tactile solution combines fingertip tactile sensors with flexible electronic skin, extending perception coverage from fingertips to the entire hand, providing a more complete information foundation for dexterous manipulation.
Xense Whole-Hand Tactile Solution
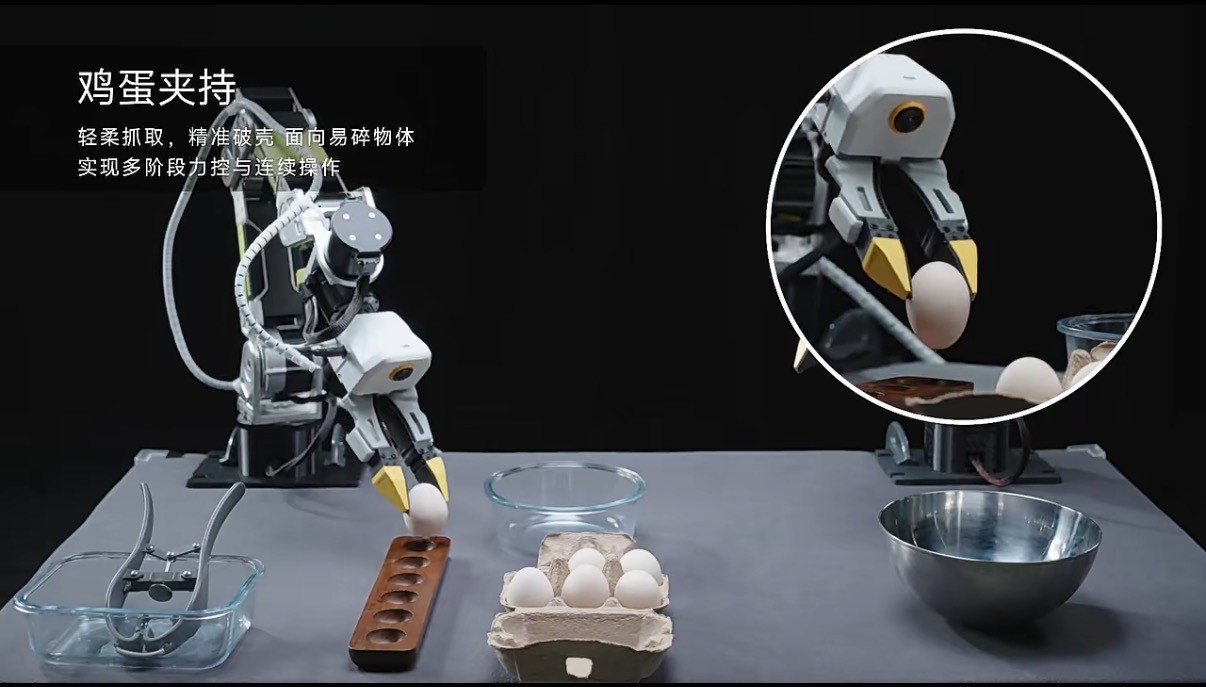
Among these, the fingertip tactile sensor relies on three-color-light visuo-tactile technology, integrating high-density perception capability within a bionic fingertip form, and can be used for tasks such as alignment, pushing, rolling contact and fine grasping, helping robots obtain richer and more detailed tactile information at the moment of contact. The palm area uses large-area flexible electronic skin, covering more dexterous hand regions and perceiving broader contact distribution and force changes.
At the booth, visitors personally experienced pressing and sliding on the fingertip, gaining a more direct feel for how the sensor captures subtle deformation and force changes.
Visitors Experiencing Touch On Site
02 XTac UMI G1
Entering a high-quality data ecosystem with an efficient data collection system
Tactile hardware solves "how to perceive," while data collection answers "how to settle perception into data." The long-term competitiveness of embodied intelligence depends on whether one has high-quality, low-cost, sustainably accumulating real interaction data.
Xense Wearable Tactile Data Collection Gripper
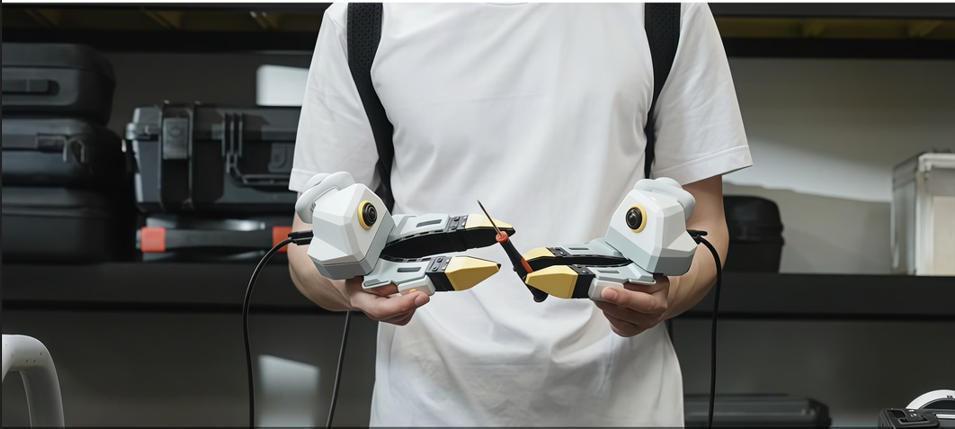
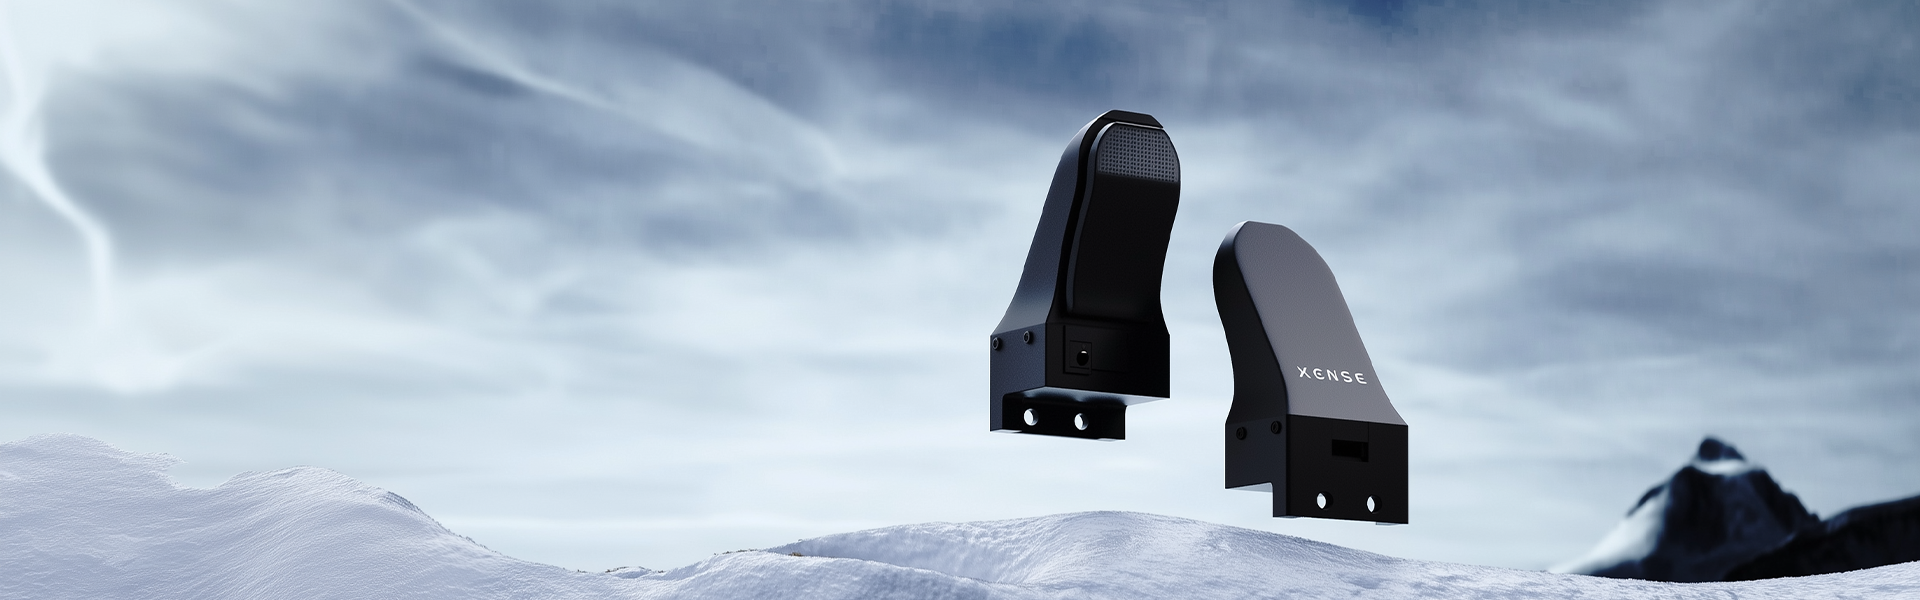
The Xense XTac UMI G1 wearable tactile data collection gripper is designed precisely for this need. It consists of a master gripper, slave gripper, backpack computing unit, headset kit and visualization terminal, capable of synchronously collecting vision, touch, pose, gripper state and IMU data during natural human-robot interaction.
The core value of this solution: it ensures high data quality — natively adapted for real-robot deployment with high data usability; and it does not require a real robot body for collection, greatly reducing the cost and threshold of data acquisition. Low cost, high efficiency and high usability make large-scale data collection possible.
At WRC, visitors used the two-finger gripper to collect data on everyday objects such as lipstick, gum and business cards, and viewed the output of visual and tactile data on computers in real time, intuitively experiencing how real manipulation data is completely and accurately collected and presented.
Hardware is just the starting point. Only when the contact information from real manipulation is preserved and becomes data that model training and product optimization can directly use does touch truly gain long-term value.
XTac UMI G1 on Display
03 Interactive Experience Zone
Delicately perceiving textures, beyond force
At WRC, Xense Robotics set up a multimodal tactile sensor interactive experience. Visitors could observe in real time the sensor's perception results of contact state changes through pressing and sliding operations, intuitively understanding how tactile information is captured, presented and applied.
Multimodal Tactile Sensor
The Xense tactile sensor series covers products including Quark N1, Elf, Photon, GS-PS and more, outputting multimodal data such as raw images, differential images, 3D visualization, tangential information, depth maps and six-axis force, supporting capabilities including 3D surface measurement, texture recognition, 3D force distribution, slip detection and motion tracking.
Mahjong Texture Recognition Experience
In the texture recognition experience, visitors gently pressed a mahjong tile onto the flat sensor, and the software interface immediately presented the clearly visible raised texture data of the tile surface — engravings, character edges and embossed depth all clearly visible, with tactile information transformed into observable, measurable digital signals. This delicate perception extends touch beyond "what was felt" to "what was discerned."
This display is not only an on-site interactive experience but also an intuitive window into Xense's tactile hardware and data capabilities: presenting tactile information in an observable, understandable and communicable way.
Looking beyond the hardware on display, Xense Robotics' long-term technology direction is becoming increasingly clear: on one hand, the coverage of tactile perception extends from fingertips to the whole hand, and from industrial scenarios to humanoid robot applications — touch is entering more and more manipulation scenarios. On the other hand, through data collection devices such as the XTac UMI G1, Xense is the first in the industry to balance the relationship among data collection cost, efficiency and quality, making real interaction data a scalable asset.
What Xense Robotics is building is a systematic capability centered on touch: acquiring real contact information through tactile hardware, settling real interaction processes through data collection systems, supporting model training with multimodal data, and ultimately continuing to deliver real robot manipulation tasks. In the process of robots moving into the real physical world, touch is not just a sensor module, but an important foundation spanning perception, data, models and applications.
In the future, Xense will continue to bring tactile technology into more real manipulation scenarios, giving robots more reliable perception, higher-quality data and more stable manipulation capabilities as they engage with the world.