内容摘要
Xense Robotics Technology (Shanghai) Co., Ltd. and ArcheBase (Shanghai) Technology Co., Ltd. recently signed a strateg…
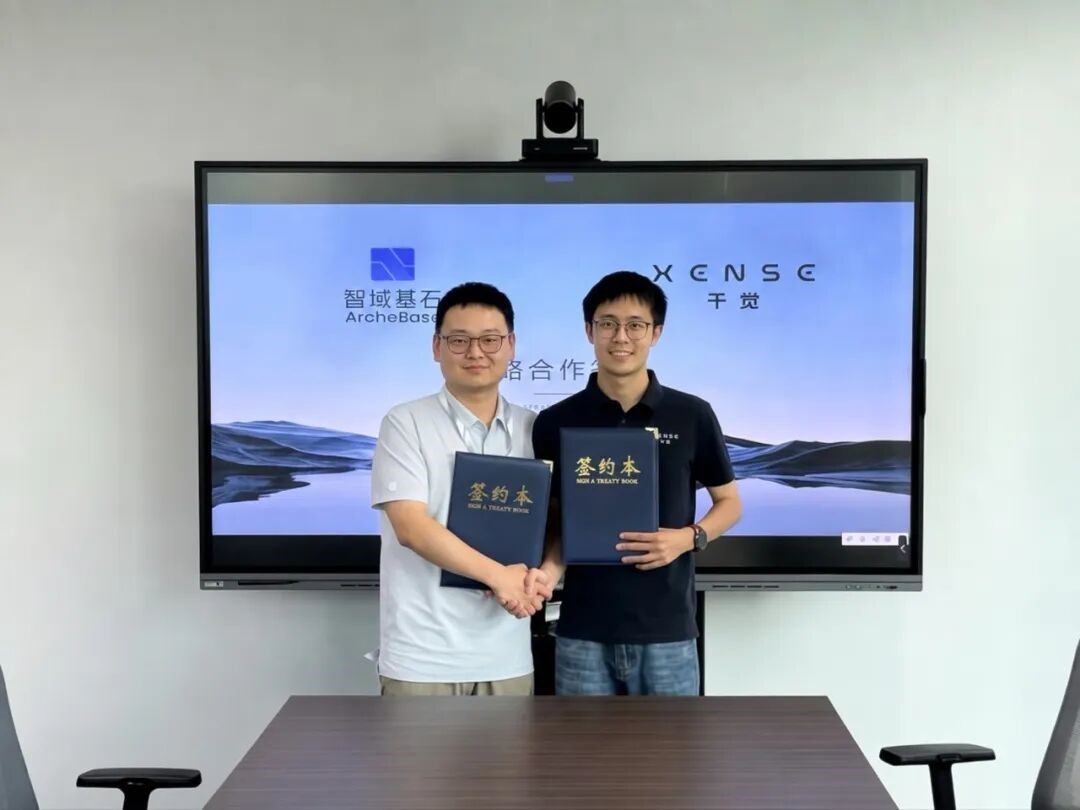
Xense Robotics Technology (Shanghai) Co., Ltd. and ArcheBase (Shanghai) Technology Co., Ltd. recently signed a strategic cooperation agreement. The partnership brings together Xense's expertise in multimodal tactile sensing, data collection devices, and tactile intelligence with ArcheBase's capabilities in physical AI data infrastructure, manipulation-level data assets, and real-task validation. The two companies will collaborate on collecting, processing, and applying robotic interaction data.
To complete complex physical tasks, robots need more than records of scenes and actions. They must also understand states, contact, failures, and recovery throughout a task. Starting with tactile sensing, the partnership will turn real interaction data into structured, reusable task data that supports robot training, evaluation, and deployment.
Xense: Capturing Real Interaction Through Tactile Sensing
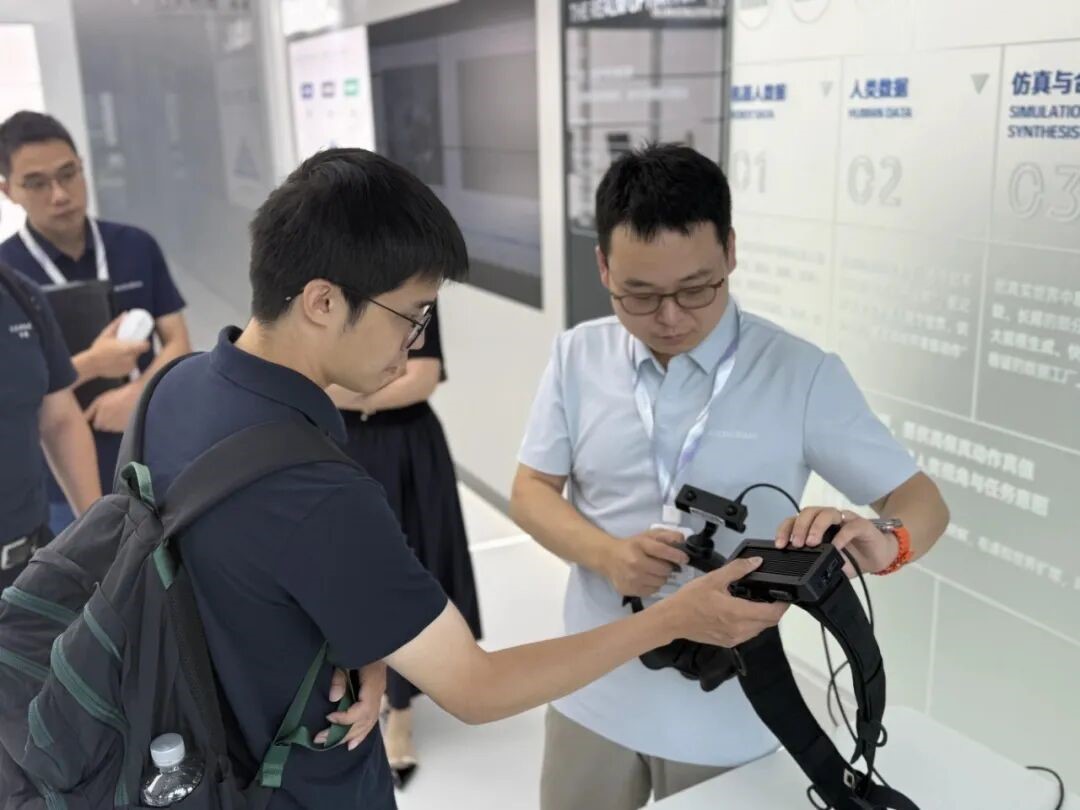
Xense has long focused on multimodal tactile sensing. Its technology portfolio includes high-precision visual-tactile sensors, tactile simulation, XTac UMI data collection devices, and tactile model development.
Visual-tactile sensors give robots multidimensional information during contact. XTac UMI collects data from real manipulation, bringing vision, touch, pose, and action into a unified acquisition workflow. By steadily accumulating real interaction data, Xense is integrating tactile information into robotic data production and model applications.
ArcheBase: Turning Task Processes into Manipulation-Level Data
ArcheBase builds physical AI data infrastructure that converts robotic task processes in real settings into manipulation-level data assets. It also provides foundational capabilities for task retrieval, failure analysis, quality checks, and version tracking.
Its data system records more than what a robot accomplished. It organizes task stages, contact events, causes of failure, and recovery paths so that the data can better support model training, task evaluation, and application development.
Xense and ArcheBase: Connecting Tactile Sensing with Manipulation-Level Data
The partners will explore the collection, processing, and use of tactile and multimodal data from real robotic tasks. They will connect tactile information to task actions, scene states, and execution results, then apply those connections to robot training, evaluation, and task development.
Xense contributes tactile sensing and data collection capabilities; ArcheBase contributes physical AI data infrastructure. Together, they will explore how to incorporate contact information into task data systems, transforming tactile data from sensing records into assets that can be used for training, evaluation, and reuse.
The companies will continue to collaborate on real physical interactions, bringing tactile data into a more complete physical AI data infrastructure and exploring its value in robot training, evaluation, and practical applications.